
Technical Glossary
2026/05/07
This technical glossary explains terms drawn mainly from Miki Pulley’s website and product catalogs.
We hope it will be useful to engineers as well as for training new employees.
The explanations were written specifically for this glossary, although some passages draw on publicly available technical literature, including JIS standards.
A
Anodizing is a surface treatment that forms an oxide coating by electrolytically treating aluminum as the anode, or positive electrode.
“Alumite,” the Japanese term commonly used for this treatment, was originally a registered trademark of RIKEN but is now widely used as a general name for anodic oxide coatings.
Aluminum is a nonferrous metal: it is a metal, but it is not iron. Because it readily reacts with oxygen, aluminum naturally forms a thin oxide film. It can therefore be used without anodizing, but may corrode in some environments, so anodizing is applied when necessary.
Miki Pulley uses anodizing on the clamping hubs of SERVOFLEX SFC-model couplings.
JIS defines an armature as a movable iron piece that forms a magnetic circuit. In Miki Pulley products, armatures are components of electromagnetic clutches and brakes. The word “movable” indicates that the armature moves during operation.
The following briefly explains the operating principle of an electrically actuated clutch/brake.
When power to the electromagnetic clutch/brake is switched on, the coil built into the stator is energized, causing the stator to act as a magnet. The stator is fixed to the machine or prevented from rotating by an anti-rotation member.
The stator and rotor are positioned next to each other with a clearance, so they do not touch. The rotor is fixed to the shaft and rotates with it.
Magnetic force from the stator passes through the rotor and attracts the iron armature, bringing it into close contact with the rotor’s friction surface. Because it moves axially when attracted, it is a movable iron piece.
A magnetic circuit is thus formed through the stator, rotor, and armature.
A pulley or other component can be attached to the armature. When the armature engages the rotor fixed to the shaft, the attached pulley also rotates with the shaft.
A ring-shaped leaf spring is installed between the armature and pulley. The spring is riveted to the armature. The customer machines the pulley—or another component—to suit the application and fastens it to the spring with the supplied bolts.
With power on, the armature is attracted toward the stator and engages the rotor. The leaf spring is then deflected into a wave-like shape. When power is switched off, the spring’s restoring force retracts the armature, interrupting power transmission.
Understanding the armature’s movement and role also helps explain the functions of the stator and rotor.
Spring-actuated brakes operate differently from electrically actuated clutches/brakes. They also contain an armature, stator, and rotor, but do not use this leaf spring.
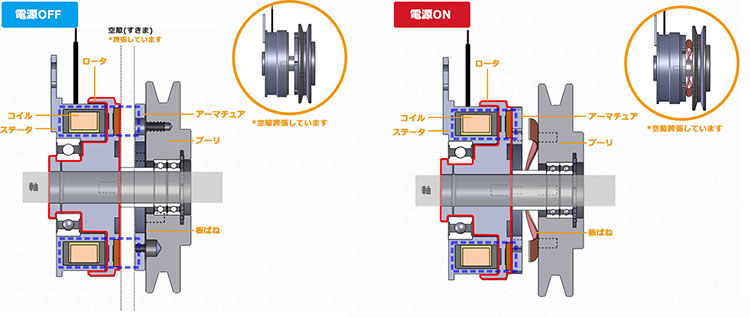
English translation of image text
Left — Power OFF:
• Clearance (air gap): disengaged
• Rotating freely
Right — Power ON:
• Engaged
Component labels:
• Rotor
• Coil
• Stator
• Armature
• Pulley
• Shaft
• Leaf spring
The axial direction is parallel to the centerline of the shaft on which a coupling is mounted.
For CENTAFLEX couplings, Miki Pulley calls bolts that secure the rubber body or element parallel to the shaft centerline “A-direction bolts,” where A stands for axial.
In specifications for permissible coupling misalignment, the same parallel direction is described as the “axial direction,” also sometimes called the thrust direction, to distinguish the terminology used for the bolts.
The corresponding perpendicular direction is the radial direction.
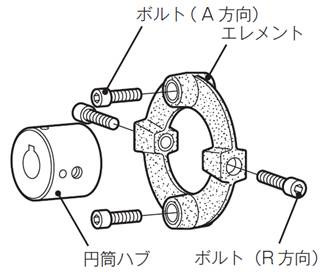
English translation of image text
• Bolt (axial / A direction)
• Element
• Cylindrical hub
• Bolt (radial / R direction)
B
Backlash is mechanical play. In a pair of meshing gears, it is the range through which one gear can move without transmitting rotation to the other.
Backlash is undesirable in machinery requiring high positioning accuracy.
Miki Pulley’s catalogs describe SERVOFLEX couplings as having “completely zero backlash.” With no mechanical play, these couplings are suitable for high-speed, high-precision positioning and ultra-precise servo control.
The coupling product-lineup pages include feature icons indicating functions and performance. Please refer to them when selecting a coupling.
English translation of image text
• Ultra-high rigidity
• Low inertia
• High responsiveness
• Zero backlash
Balance quality describes the relationship between a rotating object’s operating speed and the vibration it produces. It can also be understood in terms of the amount and angular location of the mass offset from the center of rotation.
In this sense, balance quality relates to the magnitude of unbalance. Correcting that unbalance—balancing—reduces vibration. JIS defines balance quality as the product of specific unbalance and maximum service angular velocity.
The opening explanation is intended to make this more intuitive without introducing unfamiliar terms immediately.
Objects inherently have some unbalance. Even individual components are affected by material nonuniformity and machining tolerances, and assembling them can accumulate these effects. These are described as static unbalance, which exists even without rotation.
A long shaft can also sag under its own weight when installed.
Rotation produces centrifugal effects. Unbalance that becomes evident during rotation is called couple unbalance. A fully balanced condition requires the centrifugal effects to cancel, which is rarely achieved perfectly in practice.
Static unbalance + Couple unbalance = Dynamic unbalance
One Miki Pulley product balanced before shipment is the SERVOFLEX SFM coupling.
Balancing normally involves measuring unbalance on a balancing machine and correcting it. Highly precise machines can reportedly detect unbalance far smaller than a grain of rice. At such precision, even a small scratch can upset the balance, requiring great care during packing. Pursuing unlimited precision would also make shipment impractical.
The customer’s operating speed and required balance quality grade are therefore important. JIS provides graphs defining permissible unbalance for each grade and rotational speed.
The numerical upper limit of balance quality is used in the grade designation, such as G2.5 or G6.3. At the same speed, G2.5 requires stricter balancing than G6.3.
For example, there is approximately 5 μm permissible specific unbalance for G6.3 at 10,000 min⁻¹, compared with 2 μm for G2.5. At 20,000 min⁻¹, the value is approximately 3 μm for G6.3. Higher speed therefore demands more stringent balancing.
Greater precision increases cost, and in some cases balancing may exceed practical limits. These requirements must be considered carefully during design.
Balance grades range from G0.4 to G4000, with reference tables recommending grades for different rotating machines. For example, G6.3 includes machine-tool and general-machinery components, while machine-tool spindles are recommended at G2.5.
Rotating machinery is not limited to industrial equipment. Fans, ventilation fans, CD players, and computer hard drives are familiar examples. Wherever objects rotate, the challenge of balance continues.
Relations between countries and people can also become unbalanced through racial, sexual, and economic discrimination. Unfortunately, no balancing machine yet exists to correct those imbalances.
A ball screw is a feed screw in which balls roll between the helical grooves of the screw shaft and nut. Rolling contact reduces friction and provides high efficiency.
It consists of a screw shaft, nut, balls, and other components, but requires a drive source to function as a transmission mechanism.
Connecting it to a motor through a coupling converts the motor’s rotary motion into linear motion. Ball screws are widely used in semiconductor manufacturing equipment, industrial robots, and machine-tool feed and positioning systems.
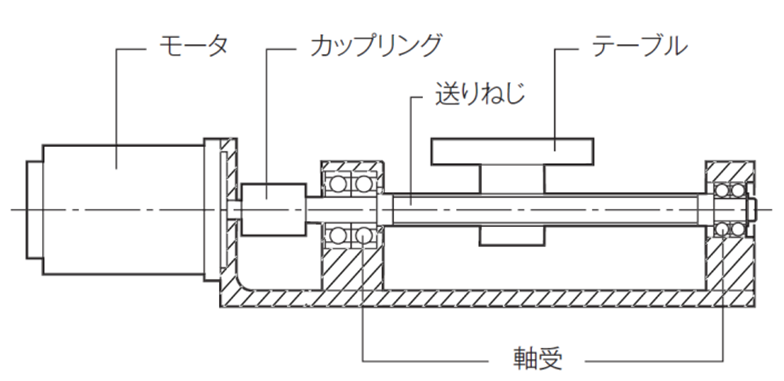
English translation of image text
• Motor
• Coupling
• Feed screw
• Table
• Bearing
A bearing is a machine element that supports a rotating shaft. The type discussed here is a rolling bearing in JIS terminology; the broader term is bearing.
Rolling bearings can be divided into four basic groups according to load direction and rolling-element type. Radial ball bearings are particularly common. “Radial” means the load acts perpendicular to the shaft centerline, while “ball” identifies the rolling elements. The other basic load direction is thrust, parallel to the shaft, and rollers are the other rolling-element type.
In simple terms, a ball bearing has several balls arranged around the circumference between metal inner and outer rings, kept apart so they do not contact one another. Shielded types prefilled with grease are available for some applications.
The purpose is to allow relative rotation between the rings rather than to transmit drive power from one ring to the other.
Why support the shaft? Even a thin or short shaft can develop some runout due to machining accuracy and centrifugal effects. At high speeds, this can become significant vibration, roughening machined surfaces or shaking the entire machine.
Supporting the shaft with plates containing holes would stabilize it initially, but direct sliding contact would produce friction, enlarge the holes, or cause seizure.
Installing bearings in the supports prevents these problems. Such assemblies are commercially available as bearing housings, bearing units, or blocks.
Passing the shaft through the inner ring allows smooth rotation with low friction. This is the bearing’s role.
Bearing accuracy classes include 0, 6, 5, 4, and 2.
Class 2 is the most precise of these and is used in applications such as high-speed machine-tool spindles.
The first illustration shows an armature of a Miki Pulley electrically actuated clutch/brake attached to a pulley. Two bearings are fitted side by side between shaft and pulley.
With the armature disengaged, the shaft can rotate while the pulley remains stationary because the bearings allow relative rotation. When power is applied, the armature is attracted to the rotor fixed to the rotating shaft, causing the attached pulley to rotate with it.
Bearings therefore play an important role in electrically actuated clutches/brakes that connect and disconnect power to a pulley while the shaft continues rotating.
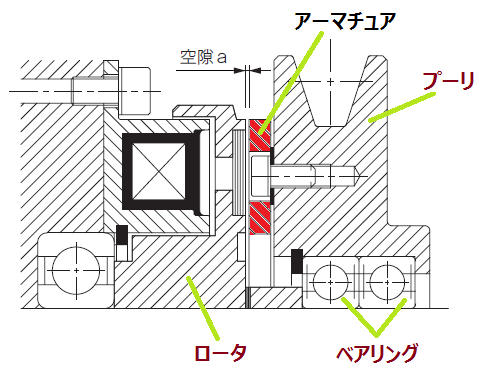
English translation of image text
• Armature
• Pulley
• Rotor
• Bearing
• Air gap a
The second illustration, from “Calculating the Natural Frequency of a Feed-Screw System” in the coupling catalog, shows bearings at both ends of a feed screw or ball screw connected to the motor through a coupling. Supporting the screw reduces the load on the motor.
Adding more bearings indiscriminately is not recommended. Adding a bearing beyond the two end supports creates a three-point support arrangement that may overload the middle bearing.
A general-purpose motor already contains two bearings supporting its shaft. Adding just one more bearing outside the motor can similarly create three-point support and overload a bearing inside the motor.
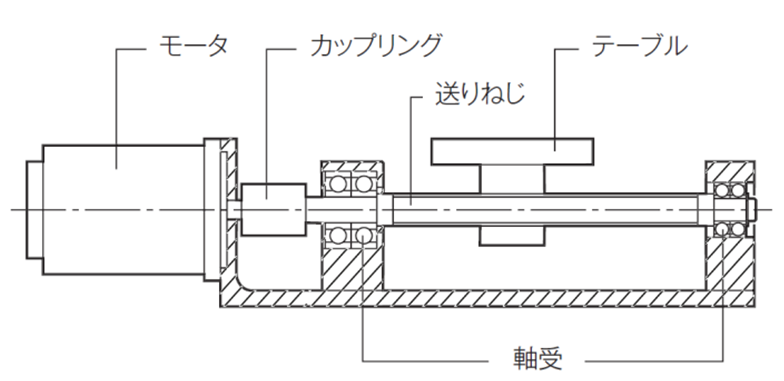
English translation of image text
• Motor
• Coupling
• Feed screw
• Table
• Bearing
A surface treatment that forms an oxide film on steel to help prevent rust. Its glossy black finish gives the treatment its name. It is also called a magnetite coating treatment because it forms an iron oxide film.
For long-term use or storage, the surface must be protected with rust-preventive oil or similar protection. Rust may develop if products are stored for a long time after purchase.
Miki Pulley uses this treatment on hubs for products such as SERVOFLEX SFS couplings and SERVORIGID couplings.
Because the coating is formed by a chemical reaction, it does not peel like plating or paint. It is also thin, although thickness depends on treatment time, so it has very little effect on dimensional accuracy.
C
CCW is the abbreviation for “counterclockwise.” Clockwise is abbreviated as CW.
For Miki Pulley’s Zero-Max stepless speed changers, select the model according to the required direction of rotation of the output shaft. Models with the number “1” rotate counterclockwise (CCW); those with “2” rotate clockwise (CW).
Separate models are necessary because of the Zero-Max mechanism: reversing the input rotation does not reverse the output rotation. Carefully consider the installation orientation of the Zero-Max unit during design. Special models are also available that allow forward and reverse rotation to be selected with a lever.
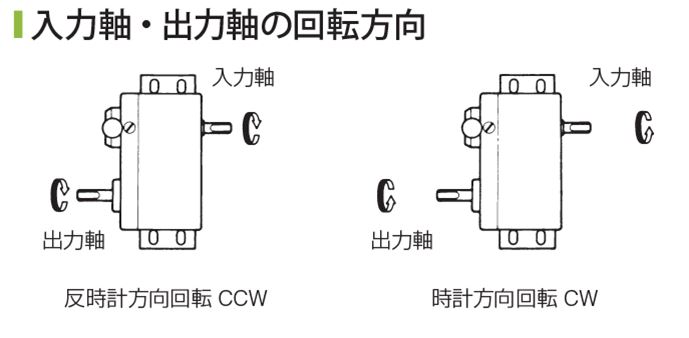
English translation of image text
• Direction of rotation of input and output shafts
• Input shaft
• Output shaft
• Counterclockwise rotation (CCW)
• Clockwise rotation (CW)
See also “Spring Pin.”
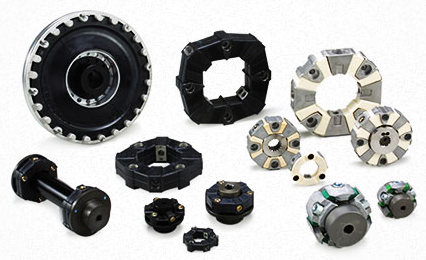
CENTAFLEX was developed by CENTA Antriebe of Germany, Miki Pulley’s technical partner. The product name comes from the company name CENTA.
CENTAFLEX belongs to the category of rubber and resin couplings for prime movers. Rubber couplings use the elasticity of rubber, and resin couplings use the elasticity of resin, to absorb and damp impact and vibration.
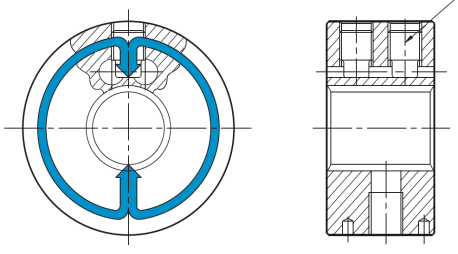
CENTALOCK is a proprietary method used in Miki Pulley’s CENTAFLEX couplings to secure a splined shaft firmly to a clamping hub, or cylindrical hub.
Tightening the clamping screw applies force around the splined portion to lock the connection.
See also “JAMP.”
chemSHERPA is a scheme developed by Japan’s Ministry of Economy, Trade and Industry to communicate information about chemical substances in products through the supply chain.
Miki Pulley investigates substances contained in its products to meet customer requirements. This includes accurately reporting information obtained through the supply chain and submitting files created with chemSHERPA tools.
A bolt used in a clamping hub. Tightening the bolt narrows the slot, also called a slit, machined in the hub, securing the hub to the shaft.
The bolt must be tightened to the specified tightening torque to ensure a reliable connection.
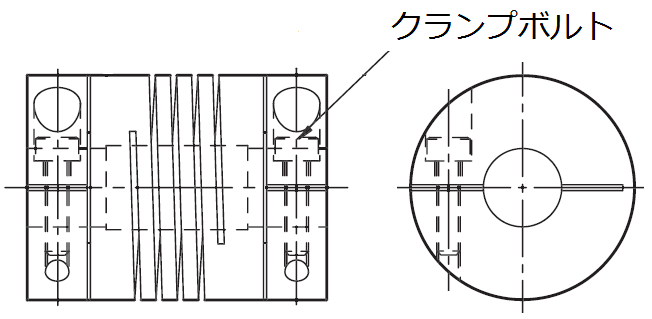
English translation of image text
Clamping bolt
This is the general term for the slotted hubs used in SERVOFLEX, SERVOFLEX RUBBER, and STARFLEX couplings. Their fastening bolts are called clamping bolts.
HELICAL couplings are one-piece products and therefore have no separate hubs, but their clamping-bolt shaft connection uses the same principle.
CENTAFLEX couplings instead use the clamping hubs and clamping screws described above. Their purpose is also to secure a hub to a shaft, but their construction differs, so the Japanese names are distinguished.
Please note that Miki Pulley’s English catalogs translate both Japanese hub names as “clamping hub.”
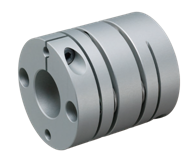
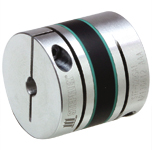
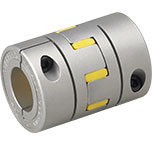
See also “Clamping Screw” and “CENTALOCK.”
A hub that uses the CENTALOCK action to secure it to a splined shaft.
For CENTAFLEX couplings, the cylindrical hub used with a clamping screw is called a clamping hub.
See also “Clamping Hub (CENTAFLEX)” and “CENTALOCK.”
In CENTAFLEX couplings, this specially shaped screw is inserted into a threaded hole in the hub. Tightening it activates the CENTALOCK mechanism to secure the clamping hub to a splined shaft.
Clamping bolts also secure hubs to shafts, but they are used in split clamping hubs such as those on SERVOFLEX SFC models.
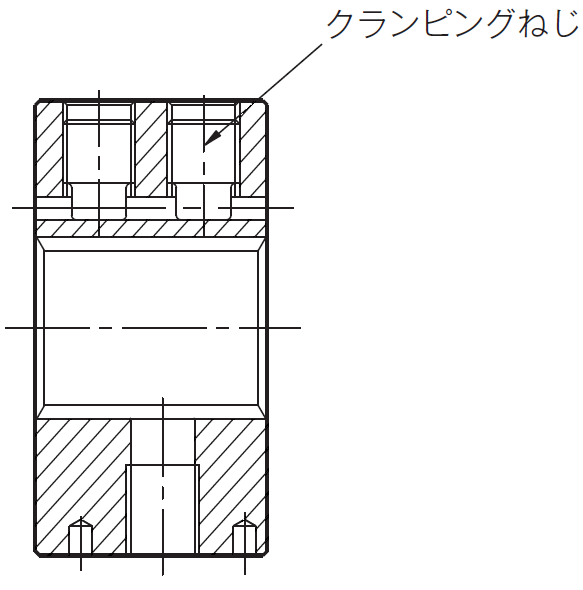
English translation of image text
Clamping screw
See also “NC Lathe.”
NC stands for “numerical control,” and CNC stands for “computer numerical control.” CNC was developed in the 1970s and remains in use today. There is now generally little need to distinguish NC from CNC; in current usage, they can be regarded as referring to essentially the same equipment.
This designation refers to standards established in 1983 that changed the shaft diameters, key widths, and tolerances of three-phase induction motors.
Miki Pulley has its own standard bore machining specifications for couplings and other products. Bores and tolerances matching those motor shafts are designated “compatible with new motor standards,” and products are sold with these bores already machined.
Customers can use them immediately without machining the bores themselves.
Approximately 35 years have already passed since 1983, so “compatible with new motor standards” is now an outdated expression; “motor compatible” would be sufficient.
This designation is sometimes mistaken for compatibility with recent high-efficiency motors, but it refers to all three-phase induction motors sold from 1984 onward.
Miki Pulley’s standard bore specifications also include “old JIS standard compatible” and “new JIS standard compatible.” The similar “new motor standard compatible” designation was adopted when these machining specifications were established and has continued to be used in the catalogs.
Please understand that this wording may be changed in the future.
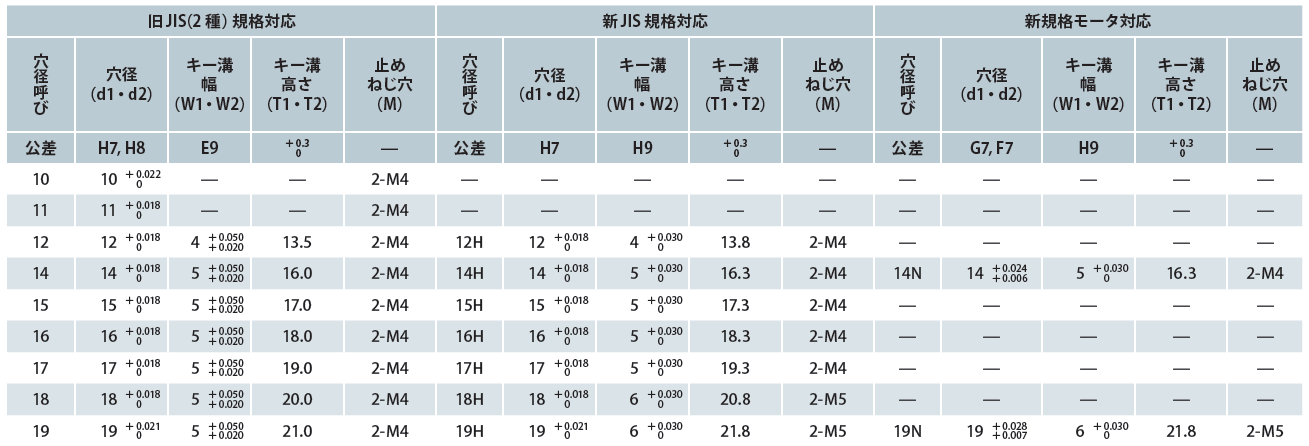
English translation of image text
Group headings:
• Compatible with old JIS Class 2 standards
• Compatible with new JIS standards
• Compatible with new motor standards
Column headings repeated for each group:
• Nominal bore designation
• Bore diameter (d1 / d2)
• Keyway width (W1 / W2)
• Keyway height (T1 / T2)
• Set screw hole (M)
• Tolerance
Tolerance designations:
• Old JIS Class 2: Bore H7 or H8; keyway width E9; keyway height +0.3/0
• New JIS: Bore H7; keyway width H9; keyway height +0.3/0
• New motor standards: Bore G7 or F7; keyway width H9; keyway height +0.3/0
The dimensions, bore designations, and thread sizes shown in the image are numerical specifications and remain unchanged.
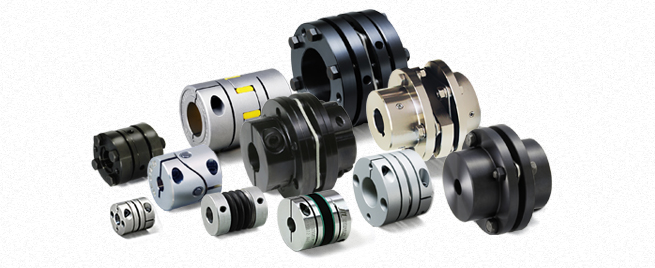
A shaft coupling connects two shafts and transmits mechanical power from one to the other.
Most shaft couplings supplied by Miki Pulley are flexible couplings. They can transmit rotation and power even when the shaft centerlines are misaligned.
Miki Pulley also supplies highly rigid couplings without this flexibility under the name SERVORIGID.
CW is the abbreviation for “clockwise.” Counterclockwise is abbreviated as CCW.
A cylindrical hub is one type of hub used to secure the rubber body or element in a CENTAFLEX coupling. It is named for its cylindrical shape.
The bolts that fasten the rubber body or element to this hub are installed perpendicular to the centerline of the coupling shaft. They are therefore called “R-direction bolts,” where R stands for radial.
A flange hub is used as the mating hub in the assembly.
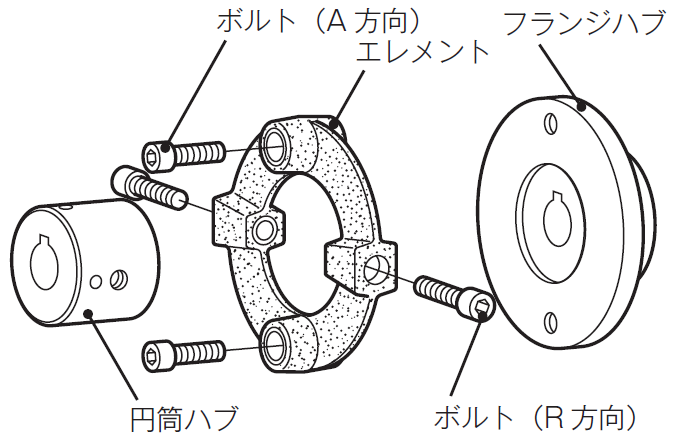
English translation of image text
• Bolt (axial / A direction)
• Element
• Flange hub
• Cylindrical hub
• Bolt (radial / R direction)
D
Damping is the gradual reduction of vibration amplitude over time. The shorter the time required for vibration to subside, the higher the damping performance.
One strength of Miki Pulley’s SERVOFLEX RUBBER is its high damping performance. Its elastic elements are made of rubber, allowing vibration to be absorbed quickly.
Flexible couplings with metal elastic elements have high torsional stiffness and excel at transmitting rotation, whereas rubber is better at absorbing vibration. Select the coupling that best matches the required machine accuracy, performance, and application.
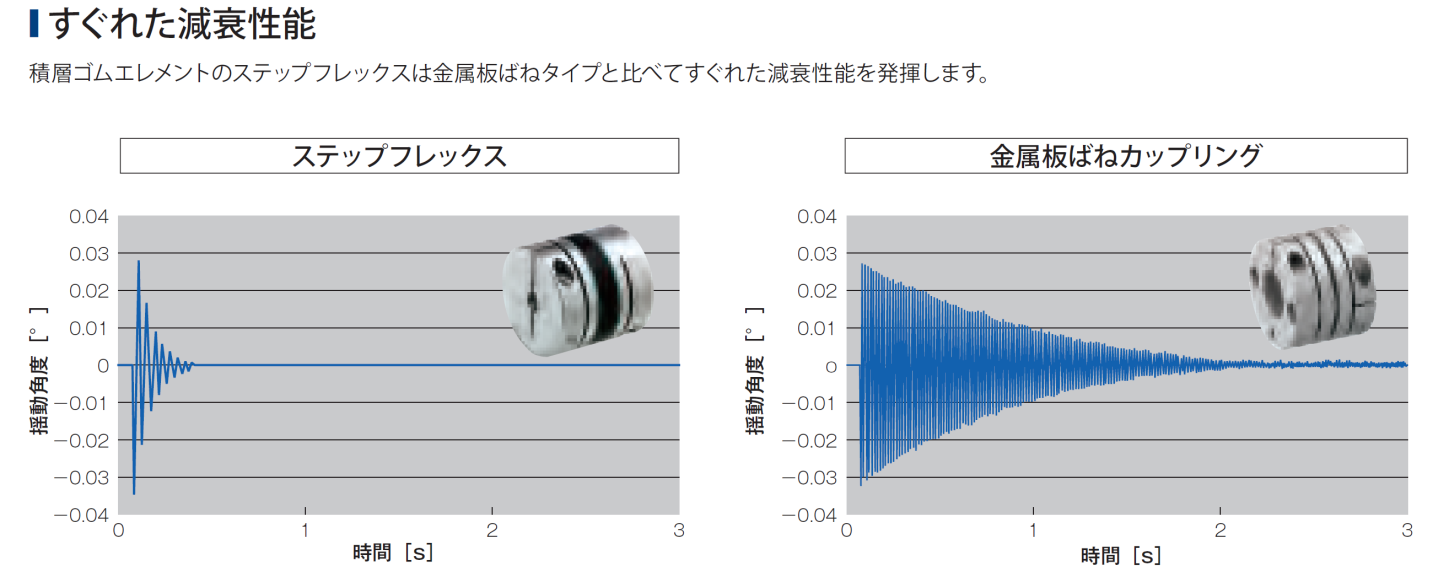
English translation of image text
Superior damping performance
STEPFLEX with laminated rubber elements provides superior damping performance compared with metal disc spring couplings.
Left: STEPFLEX
Right: Metal disc spring coupling
Vertical axis: Oscillation angle [°]
Horizontal axis: Time [s]
In JIS terminology, a level is the logarithm of the ratio of a quantity to a reference quantity of the same kind. With base-10 logarithms, the unit is the bel; one decibel is one-tenth of a bel. Simply put, decibels express the ratio of two quantities.
“Deci” is the same prefix used in deciliter: 1 dL = 0.1 L. In SI, it denotes one-tenth, or a factor of 0.1.
Sound-related quantities include sound intensity, sound energy density, and sound pressure.
The decibel was originally devised to describe telephone-signal attenuation, but its usefulness for expressing ratios has led to applications in vibration, electricity, optics, and other fields.
Sound is vibration in air and can be described as small pressure changes. Sound pressure is measured in pascals [Pa]. The range is 0.00002 to 20 Pa—a ratio of one million to one. Such a range is awkward to express directly, so logarithms compress it into a manageable scale. This illustrates what is meant by “the logarithm of the ratio of a quantity to a reference of the same kind.” For sound, decibels are obtained by converting a sound-pressure ratio into a level.
The unit is attached to values derived from physical measurements. Noise measurements are adjusted using frequency weighting such as the A-weighting of a sound level meter. Environmental vibration measurements similarly apply corrections to measured vibration amplitudes.
Frequency is central to these corrections. Noise is not perceived solely according to intensity, nor vibration solely according to amplitude. Decibel values can incorporate frequency-dependent adjustments reflecting human perception.
Frequency is the number of cycles per second, measured in hertz [Hz]. The human audible range is said to be 20–2,000 Hz. Lower frequencies are perceived as lower-pitched sounds, and identical sound pressures can be perceived differently at different frequencies.
Sound level is expressed in decibels using sound pressure, while pitch is associated with frequency in hertz.
For example, the threshold of hearing can be assigned 0 dB. This does not mean silence or the absence of sound; it identifies a reference threshold. A literal zero reference could not be used in a ratio, since multiplying zero by any number still gives zero.
Zero decibels therefore corresponds to a ratio of one, or 100%. Because decibels express ratios, they can be used far beyond acoustics. For amplitude ratios, the logarithmic scale gives 20 dB for a factor of 10, 40 dB for 100, and 60 dB for 1,000.
The machine or component driven by a prime mover. The term can also refer to a rotating driven part, such as a ball screw.
E
See also “Export Control Classification Certificate.”
EAR refers to the Export Administration Regulations under U.S. law. Products and technologies containing U.S.-origin items are subject to these regulations. Those without such content are outside their scope.
These regulations therefore affect trade worldwide. For example, products containing U.S.-origin items may be subject to the EAR when exported from Japan to China.
EAR classification must therefore be considered even if the United States is neither the exporting nor the destination country.
When products or technologies containing U.S.-origin items are exported from Japan to another country, they fall under the EAR’s reexport controls. A U.S.-origin item in Japan has already been exported from the United States to Japan; exporting it onward is therefore called a “reexport.”
Some Miki Pulley products are imported from the United States, including HELICAL couplings and certain Zero-Max stepless speed changer models. The “Export Control Classification Certificate” service on our website therefore includes an EAR classification field. These products are classified as EAR99 rather than as outside the scope of the EAR.
Miki Pulley uses “element” to describe the key component that transmits power in a coupling.
Elements may be made of metal, resin, or rubber. They have the greatest effect on coupling performance, particularly torsional stiffness and permissible mounting misalignment. In Japanese, they are sometimes described as cushioning members.
Components with other names, such as the “spider” in SPRFLEX couplings and the “metal coil spring” in BAUMANNFLEX couplings, perform the same function as an element.
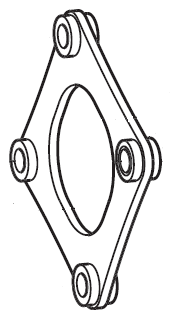
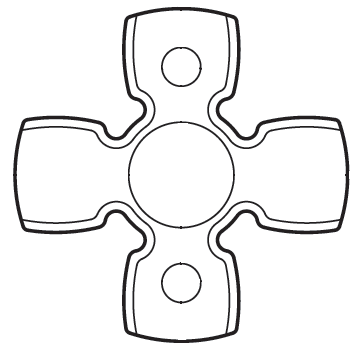
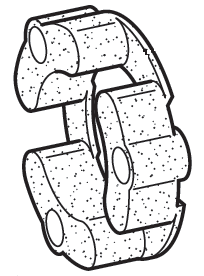
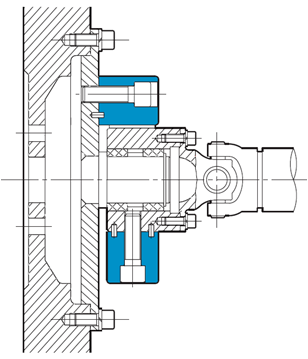
An engine generally converts energy into mechanical power. In this context, it refers to an internal combustion engine, one type of prime mover that generates power. The English word “engine” can also refer to a locomotive. The illustration shows an application in which an engine flywheel—the component on the left—is connected to a drive shaft by a CENTAFLEX CF-A coupling, shown in blue.
Equivalent moment of inertia is the combined inertia of interconnected components referred to a driving or control shaft.
Suppose gear A on a motor shaft meshes with gear B on a load shaft at a different speed. To select a motor, the required torque is obtained by multiplying inertia by angular acceleration. The inertia must therefore be expressed at the motor shaft. This is the equivalent moment of inertia referred to the motor shaft.
Consider only the two meshing gears. It may seem that their individual moments of inertia can simply be added. But they are linked and rotate at different speeds. The equivalent inertia depends on which gear is the driving gear, affecting the required drive capacity.
A smaller required drive capacity is generally preferable.
The inertia of interconnected machinery cannot therefore be found by simply adding all component inertias.
With gear A as the driving gear, the formula is:
Equivalent moment of inertia = Inertia of gear A + Inertia of gear B × (Number of teeth on gear B / Number of teeth on gear A)²
The key points are to multiply the load-side inertia by the square of the speed ratio and to take care with the denominator: when tooth counts are used, the driving gear tooth count is the denominator.
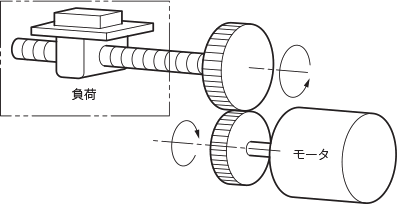
English translation of image text
• Load
• Motor
Normally, the driving gear is smaller, with fewer teeth and a smaller outside diameter, to reduce speed. Most machines use a motor as the prime mover, and the motor’s high speed must be reduced for the actual operation.
For example, if gear A has 22 teeth and gear B has 44, gear A must rotate twice for gear B to rotate once. This is a speed ratio, reduction ratio, or transmission ratio of 2.
A value greater than 1 indicates that driven gear B rotates more slowly.
Miki Pulley’s belt-type stepless speed changer unit specifications show speed ranges such as 1:4. For an output range of 500–2,000 min⁻¹, the maximum speed is four times the minimum.
Adding a reducer with a ratio of 1/20 changes the output range to 25–100 min⁻¹. Combinations can thus be selected to suit the application.
See also “Pascal’s Principle.”
ETP BUSH is a friction locking device supplied by Miki Pulley that secures a shaft and hub by pressurizing a pressure medium. Simply put, an ETP BUSH inserted between the shaft and hub expands to lock them together.
ETP BUSH friction locking devices combine ease of installation with high precision when connecting shafts and hubs.
See the videos “ETP-E Friction Locking Device: Operating Principle” and “ETP-A Friction Locking Device: Operating Principle.”
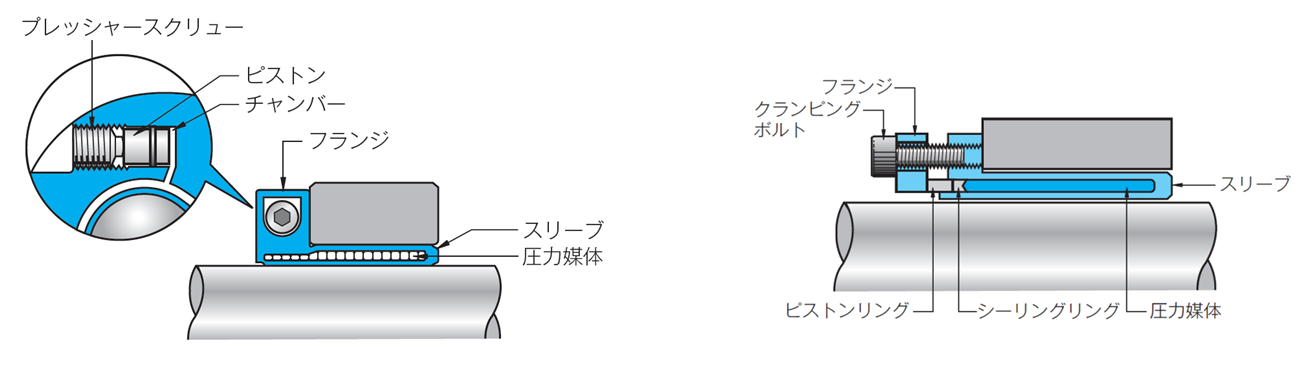
English translation of image text
• Pressure screw
• Piston
• Chamber
• Flange
• Sleeve
• Pressure medium
• Flange clamping bolt
• Piston ring
• Sealing ring
See also “EAR Classification.”
When exporting goods or providing technologies, including software, an assessment is made to determine whether an export license is required. Its purpose is to prevent weapons and goods or technologies that could be diverted to military use from reaching parties that may threaten international security.
An export control classification certificate is sometimes called a certificate of non-applicability.
Customers are responsible for determining whether an export license application is required when exporting their products or machinery. Because assessing individual Miki Pulley products may be difficult for customers, Miki Pulley classifies its own products in advance and publishes the results through the “Export Control Classification Certificate” service on its website.
The assessment determines whether a product is subject to statutory list controls, catch-all controls, or other applicable controls.
List control classification is based on whether the product falls under Items 1–15 of Appended Table 1 of the Export Trade Control Order or the Appended Table of the Foreign Exchange Order. Catch-all control classification is based on whether it falls under Item 16 of those tables.
Miki Pulley also assesses products under U.S. reexport controls through EAR classification.
F
A flange is a rim-like projection from a component, such as the large-diameter portion of a flange hub. The term can also refer to an entire component with this shape.
A flange hub is one type of hub used to secure the rubber body or element in a CENTAFLEX coupling.
The bolts connecting the flange hub to the rubber body or element run parallel to the centerline of the coupling shaft. They are called A-direction bolts, where A stands for axial.
A cylindrical hub is used as the mating hub.
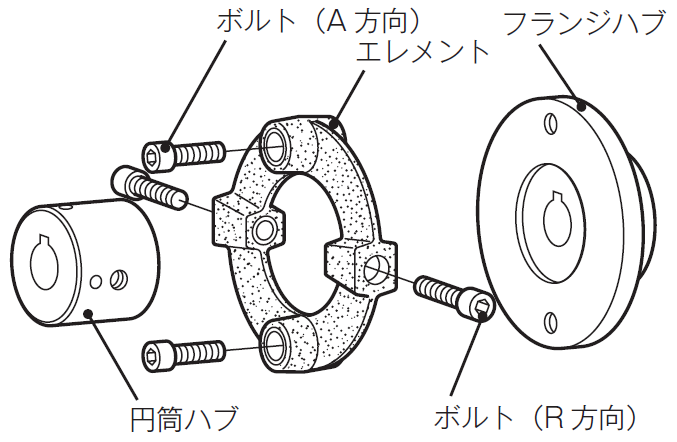
English translation of image text
• Bolt (axial / A direction)
• Element
• Flange hub
• Cylindrical hub
• Bolt (radial / R direction)
See also “CENTAFLEX.”
A flywheel is a disc used to stabilize rotation through inertia.
In an engine, simply transmitting the reciprocating motion of pistons driven by combustion to the crankshaft does not produce perfectly smooth rotation. A flywheel uses inertia to smooth the fluctuations.
If the flywheel alone is insufficient, mounting a CENTAFLEX coupling directly to it and connecting it to the shaft allows CENTAFLEX to absorb vibration, producing much steadier rotation.
CENTAFLEX couplings are therefore widely used in engine-driven systems, including construction machinery such as excavators and connections between marine engines and propulsion equipment.
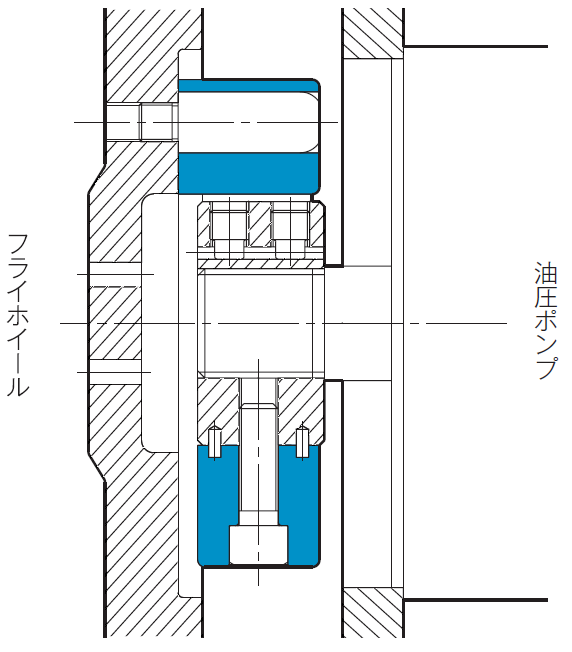
English translation of image text
• Flywheel
• Hydraulic pump
G
Gain is the ratio of output to input voltage, current, or power in a control system, often expressed in decibels. It indicates how much an input is amplified at the output.
Terms such as “high gain” and “gain adjustment” are frequently used with high-speed, high-precision motors such as servo motors. Increasing gain increases the control response, helping achieve greater precision and speed. Modern servo systems can adjust gain automatically through auto-tuning.
If gain is set too high, however, the motor can overshoot the target and then move back toward it. This repeated movement becomes vibration, requiring manual gain adjustment.
Gain settings include position, speed, and torque control. Optimizing these together enables high precision and high-speed operation.
Miki Pulley’s SERVOFLEX RUBBER rapidly damps the vibration that can occur at high gain, enabling stable high-speed control.
See “Reducing Servo Motor Vibration at High Gain.”
The video introduces a solution for high-gain servo vibration and stepper motor pulsation at resonance: replace metal couplings such as SERVOFLEX or HELICAL with SERVOFLEX RUBBER, which uses high-damping laminated rubber elements.
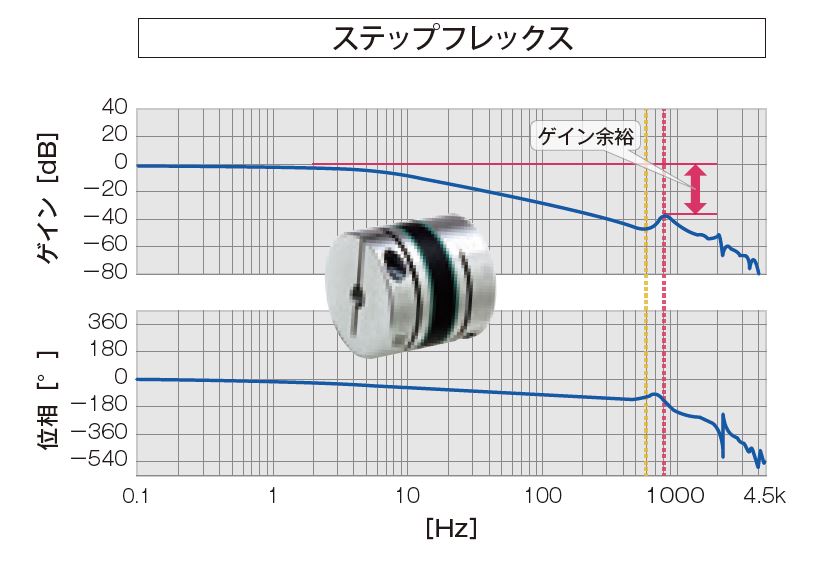
English translation of image text
• STEPFLEX
• Gain [dB]
• Phase [°]
• Gain margin
• Frequency [Hz]
A gantry is a movable, portal-shaped structure. A gantry mechanism moves a bridge-shaped member along two parallel tracks—imagine a pedestrian bridge moving along the sidewalks on either side of a road.
SERVOFLEX couplings are suitable for gantry mechanisms because high torsional stiffness is needed to synchronize the two tracks and ensure smooth motion.
A common example is a gantry crane, which travels on rails at a port to load and unload containers from ships.
Green procurement means purchasing goods with a low environmental impact, or giving preference to manufacturers that consider environmental impacts and have suitable environmental management systems.
It encourages both purchasers and suppliers to help build a society with a lower environmental burden.
Miki Pulley publishes its Environmental Protection Policy under Corporate Information on its website. The policy includes an Environmental Philosophy and Basic Environmental Policy. One of the basic commitments is to “actively promote the provision of green products to society.”
H
Hammering means lightly tapping a component with a hammer to adjust its position.
For SERVOFLEX SFF couplings, the alignment instructions call for adjusting the flange by lightly tapping its outside circumference and end face.
See also “Hexagon Head Bolts: Shapes and Dimensions.”
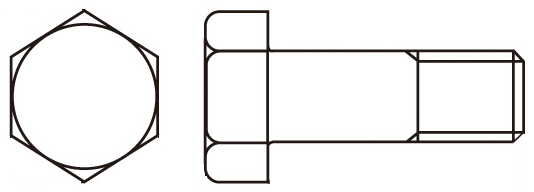
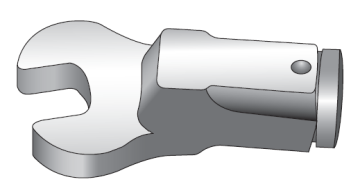
This is the general term for a bolt with a hexagonal head. Tighten it with a head or attachment that fits the external hexagon, such as a spanner-type head.
Miki Pulley uses these bolts in various products. Some POSI LOCK mechanical shaft locking devices use hexagon head clamping bolts. The friction locking hubs of SERVOFLEX couplings also use hexagon head bolts as pressure bolts.
Hexagon socket head cap screws are another common fastener type and require a hex key or hexagonal bit.
Socket head cap screws require substantially more tightening space in this application, so select a hexagon head bolt version when sufficient space is difficult to provide.
See also “Hexagon Socket Head Cap Screws: Shapes, Dimensions, and Standards.”
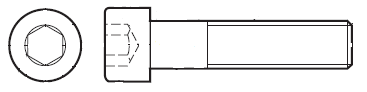
This fastener has a head with a hexagonal socket.
Tighten it with a matching hexagonal bit or hex key.
Socket head cap screws are among the most widely used components in Miki Pulley products. In couplings, they are used as clamping bolts and A- and R-direction bolts.
They are also commonly used to secure Miki Pulley products to customers’ machine bases.
Use a torque wrench or torque driver and control tightening torque according to the fastener’s strength class. Both insufficient and excessive torque can cause loosening.
Some coupling fasteners have special surface treatments or thread-locking measures, depending on the product.
Handle them with particular care.
Although Japanese commonly calls all these fasteners bolts, the English term here uses “screw,” whereas a hexagon head bolt uses “bolt.” The distinction here is typical use: a bolt is used with a nut, while a screw is used without one.
A typical bolt-and-nut example is the fitted bolt used in SERVOFLEX SFS couplings, which the customer secures with a nut.
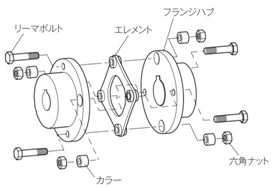
English translation of image text
• Fitted bolt
• Element
• Flange hub
• Collar
• Hexagon nut
See also “Hexagon Socket Set Screws: Shapes and Dimensions” and “How to Use Hexagon Socket Set Screws.”
A set screw uses its tip to prevent movement between machine components. “Hexagon socket” describes the recess receiving the tightening tool, not the shape of the working tip.
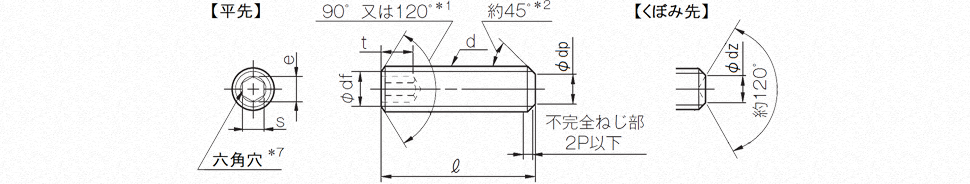
English translation of image text
• Flat point
• Cup point
• Hexagonal socket, note *7
• 90° or 120°, note *1
• Approximately 45°, note *2
• Incomplete thread: 2P maximum
• Approximately 120°
Dimension symbols and note numbers are retained as shown. The referenced footnotes are not included in this cropped image.
Tip forms include flat point, cone point, dog point, and cup point. Because the tip bears directly against the shaft or sometimes a key, tip shape is an important selection factor.
Cup-point set screws are common. They leave a circular indentation on the shaft. A complete circular mark indicates contact around the full rim of the cup and strong holding action.
The poor example shown may indicate insufficient tightening or an unsuitable relationship between shaft diameter and screw size.
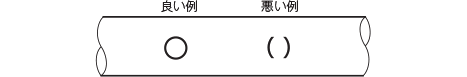
English translation of image text
• Good example
• Poor example
A set screw is normally slightly smaller than the key width. For example, a 10 mm-wide key may use an M8 set screw.
If no key is used, machining a flat on the shaft, sometimes called a D-cut, allows fuller contact with the screw tip and improves holding.
Two set screws are common. They generally hold more strongly than one, though the holding force is not simply doubled. They are often positioned 90° apart, partly to avoid interference. Larger screws may need a wider angle such as 120°.
Holding force also depends on shaft material. Select the best combination of shaft diameter and material, screw size and length, and installation angle. Proper tightening torque control is essential.
Set screws are often used together with keys. Under strong or continuous vibration, they may loosen. A loosened screw can be ejected from the rotating shaft at high speed and is dangerous.
Loosening may also increase play between key and keyway, allowing the key to move or fall out and potentially damaging the keyway.
A loose set screw can therefore have serious consequences. Customers using Miki Pulley couplings with standard pre-machined bores and keyways should handle and tighten the set screws carefully.
An HS code is a code assigned to internationally traded goods under the HS Convention. The International Convention on the Harmonized Commodity Description and Coding System is administered by the World Customs Organization (WCO).
In Japan, a nine-digit number corresponding to the goods must be entered on import and export declarations submitted to Customs.
This is called the “statistical code.” The first six digits form the HS code. Because countries classify goods under the same rules, the same HS code identifies the same category of goods.
Statistical codes and HS codes are used to identify applicable tariff rates. Rates vary by country, but the common classification makes it possible to look up a destination country’s tariffs without knowing its local language.
I
See also “Sprocket.”
Belts and chains stretch slightly during use. The resulting slack can cause vibration and noise and affect power transmission.
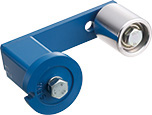
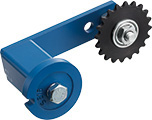
A tensioner removes this slack. The component attached to the tensioner that contacts the belt or chain is called an idler.
Miki Pulley supplies products with tensioning functions.
ROSTA tensioners include the RSE model with a pulley idler and the NSE model with a sprocket idler. Some L-model belt-type stepless speed changers also have a tension pulley with a similar function—the black component in the right-hand illustration.
ROSTA tensioners are installed with an appropriate preload applied to the belt or chain.
Their rubber elements absorb slack, vibration, and noise while automatically adjusting and maintaining proper tension. Repeated manual tension adjustment during operation is therefore unnecessary.
Removing slack also increases the contact between the belt and pulley, or between the chain and sprocket teeth, by increasing the wrap angle. This helps improve transmission efficiency.
See also “Motor” and the technical reference “Premium Efficiency Motor Specifications.”
IE codes indicate the efficiency classes of three-phase induction motors. Motor efficiency is divided into four classes:
• IE1: Standard Efficiency
• IE2: High Efficiency
• IE3: Premium Efficiency
• IE4: Super Premium Efficiency
IE stands for “International Energy-efficiency Class.”
Three-phase induction motors became subject to the Top Runner Program under Japan’s Act on the Rational Use of Energy in April 2015. The regulations require premium efficiency, equivalent to IE3, for three-phase induction motors with outputs of at least 0.75 kW and annual production of at least 1,500 units.
Higher efficiency classes convert electrical energy into rotational energy more efficiently and reduce slip losses. As a result, motor speed increases.
JIS compliance maintains mounting compatibility. However, premium efficiency motors have larger overall dimensions than standard efficiency motors, so care is required when replacing them.
Miki Pulley uses three-phase induction motors in electromagnetic clutch/brake units, hollow-shaft speed changers and reducers, solid-shaft speed changers and reducers, and belt-type stepless speed changer units. Motors rated 0.75 kW or higher are IE3; motors below 0.75 kW are IE1.
An inverter controls motor speed continuously by adjusting the frequency and voltage of the AC power supplied to the motor.
Originally, “inverter” referred to a device that converts DC to AC, while a “converter” converts AC to DC. The term inverter subsequently came to refer to a motor control device incorporating circuitry that allows output frequency and voltage to be set as required.
Before inverters, motors generally ran at a fixed speed, so mechanical devices such as Miki Pulley’s belt-type stepless speed changers were used to change speed. Japan also has both 50 Hz and 60 Hz power regions, while power conditions vary internationally, requiring additional measures to obtain the desired speed.
Inverters allow motor speed to be selected freely, making it possible to run one process faster and another more slowly.
Modern inverters provide high motor efficiency and low rotational vibration even at low speeds. Energy saving and reduced CO₂ emissions are also standard considerations.
Drawing on many years of experience and its own design approach, Miki Pulley offers inverters with functions suited to a wide range of small-capacity applications. Output frequency can be set up to 400 Hz, and automatic energy-saving control is standard.
See also “Spline.”
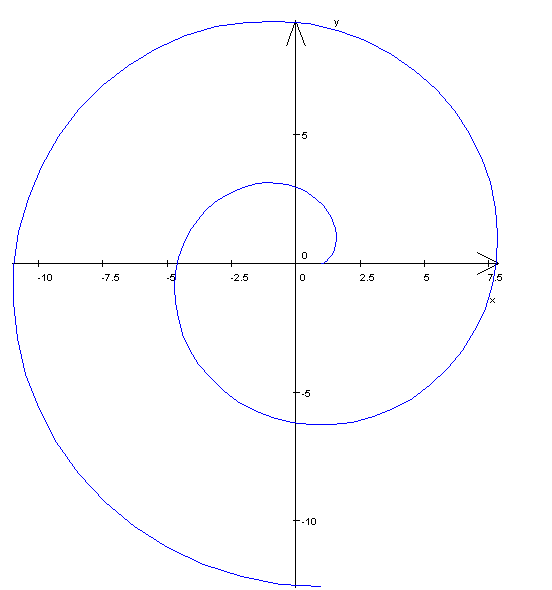
An involute curve is the path traced by the end of a taut string as it is unwound from a spool.
In the spline connection used in CENTAFLEX CF-H couplings, one possible tooth profile is an involute curve. Splines machined with this profile are called involute splines.
Involute splines offer high power transmission capacity and are relatively easy to machine.
J
See also “chemSHERPA.”
JAMP stands for Joint Article Management Promotion-consortium. It was established in September 2000 to develop appropriate management of information on chemical substances in products and smooth information transfer throughout the supply chain.
“Article” refers to components, molded products, and similar items.
JAMP works through the following specialist committees:
(1) Management Guidelines Technical Committee: develops and promotes guidelines for properly managing chemical substances in articles.
(2) Promotion Committee: promotes chemSHERPA.
(3) Tool Committee: maintains and improves chemSHERPA data preparation support tools.
(4) Declarable Substances Committee: monitors regulations and standards and maintains criteria and substance lists for management.
JIS refers to Japan’s national standards and stands for “Japanese Industrial Standards.” These are commonly called JIS or JIS standards.
Following a legislative amendment, the Japanese name changed from Nihon Kogyo Kikaku to Nihon Sangyo Kikaku on July 1, 2019, in the first year of the Reiwa era, which began on May 1, 2019. The English name remains unchanged.
K
See also “Dimensions and Tolerances of Parallel Keys and Keyways,” excerpted from JIS B 1301, “Keys and Their Corresponding Keyways.”
A key is a machine element that connects a round shaft to a hub, such as a gear or pulley.
Although the same English word is used for a house or car key, a power transmission key is a different component.
Simply inserting a shaft into a hub with a round bore allows the parts to slip under load, preventing power transmission. A key is one way of securing them against relative rotation. Power is transmitted through the key, making its strength literally a key consideration.
Keys are generally used with keyways. Several types exist, but the parallel key is the most common. JIS also specifies taper keys and Woodruff keys.
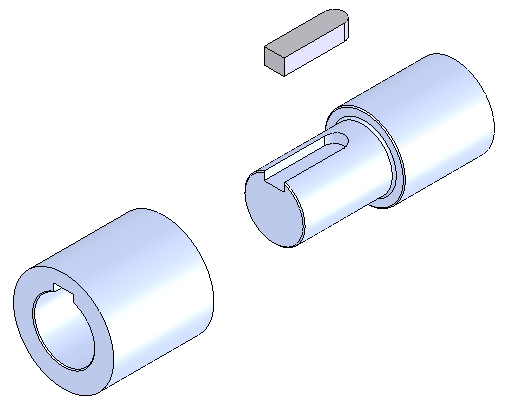
A parallel key is essentially a rectangular metal bar. Types are further classified by their ends: both ends round, both ends square, or one end round. The illustrated key has one round end.
Keyways are grooves machined in both the shaft and hub to receive the parallel key. This arrangement is called a sunk key connection.
For keyed connections to customer equipment, Miki Pulley offers many couplings, electromagnetic clutches/brakes, belt-type stepless speed changers, and torque limiters with pre-machined bores and keyways.
Some shafts, such as servo motor shafts, have no keyway.
Others are tapered, becoming slightly smaller toward the end. For these applications, keyless options include ETP BUSH friction locking devices and SERVOFLEX couplings with clamping hubs for tapered shafts.
L
A lathe is a machine tool that holds a workpiece in a chuck and rotates it while a cutting tool removes material.
LED stands for “light-emitting diode.” The semiconductor that produces light when an electric current passes through it is called an LED chip.
LED chips are made by growing crystals on a sapphire substrate using gases containing nitrogen, gallium, and other elements. This growth process forms stacked films, including a P layer, an N layer, and a light-emitting layer. Electrodes and protective films are then added to complete the chip.
The P-type semiconductor has a shortage of electrons, meaning it contains many holes, while the N-type semiconductor has an excess of electrons. A PN junction between these two semiconductor types forms the basic structure.
When a forward voltage is applied, electrons and holes move toward one another and combine in a process called recombination. Electrons initially have higher energy; after recombination, their energy is lower. The energy difference is converted into light. This is how an LED chip emits light.
LED chips are arranged on a printed wiring board and combined with other components to create a usable light source, called an LED module. The module is then combined with a driver and other components to form the light-source unit of an LED lighting fixture.
Red LEDs were invented first, followed by yellow-green LEDs. Japanese researchers Isamu Akasaki, Hiroshi Amano, and Shuji Nakamura subsequently invented blue LEDs and received the Nobel Prize in 2014. Blue LEDs completed the three primary colors of light, enabling white LED lighting.
Miki Pulley uses LEDs in inverter displays that show rotational speed and other information.
A locking ring assembly combines two tapered rings—an outer ring and an inner ring—to connect a shaft and hub.
RINGFEDER of Germany is the original manufacturer of the product, marketed as “Locking Devices.” Its simple, compact structure uses the wedge action of two tapered rings to secure the shaft and hub.
The rings cannot function alone. The customer’s hub must be bored to accommodate them, and a pressure flange and clamping bolts are needed to apply force after the rings are inserted between shaft and hub.
Multiple ring assemblies may be used according to the required torque.
Miki Pulley uses them in its FRICTION PACK ring-type shaft locking devices. The convenient FRICTION PACK combines an RfN 8006 assembly, pressure flange, and clamping bolts in a set.
Miki Pulley also offers POSI LOCK mechanical shaft locking devices using wedge action. Select according to shaft diameter, mounting method, and available space.
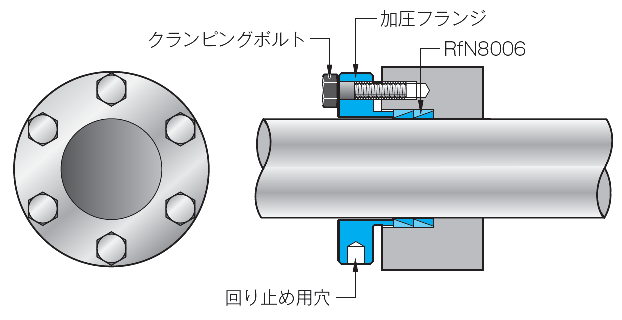
English translation of image text
• Clamping bolt
• Pressure flange
• RfN 8006
• Anti-rotation hole
In synchronized control, loss of synchronism occurs when the phase difference between two machines becomes so large that stable operation is no longer possible.
Causes include a sudden heavy load or accumulated control errors that cause the machines to drift out of synchronization.
For example, two separately installed conveyors can be synchronized by matching their drive motor speeds. Sensors detect and compare each conveyor’s output speed, and correction signals are sent to the motors.
The controller performs this correction.
A tachogenerator was once widely used to detect output speed. It generates a voltage proportional to speed, but its analog output limits accuracy. Rotary encoders are now used instead.
Miki Pulley offers OPC controllers that synchronize machines through position control. To meet today’s demand for high accuracy, OPC controllers continue to evolve, including the addition of synchronization-signal and loss-of-synchronism outputs to support complete synchronized control.
M
See “MC.”
See also “SI Units: Reference and Conversion Tables.”
Mass is the quantity of matter in an object and is independent of gravity. Its SI unit is the kilogram [kg].
An object experiences gravitational attraction from the Earth and centrifugal force due to the Earth’s rotation. The resultant is the effective gravity acting on it.
An object weighs slightly less at the equator than at the North Pole because centrifugal force changes the effective gravity.
The gravitational system of units formerly expressed weight in kgf, or kilogram-force. This unit explicitly represents a force caused by gravity. The International System of Units (SI) was adopted in place of that system to provide a unified framework using mass independently of gravity.
Mass [kg] and weight are different quantities, related by:
Weight = Mass × Gravitational acceleration
An object falling under gravity accelerates at approximately 9.8 m/s², called gravitational acceleration.
Newton’s second law states:
Force = Mass × Acceleration
One newton [N] is the force that gives a mass of 1 kg an acceleration of 1 m/s².
Thus:
1 kgf = 1 kg × 9.8 m/s² = 9.8 kg·m/s² = 9.8 N
A mass of 1 kg therefore experiences a gravitational force of approximately 9.8 N.
See also “NC Lathe.”
MC stands for “machining center.” On NC machine tools such as NC lathes, machining is controlled automatically, but cutting tools may need to be replaced manually. A machining center automates tool changes as well, enabling unattended operation.
MC and NC are sometimes thought to mean the same thing because the abbreviations are similar and both involve automated machining. Their meanings, however, are different.
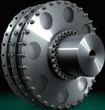
“Membrane” normally means a thin film. In Miki Pulley’s CENTAX couplings, it refers to a thin plate.
In the image, the membrane is the large circular component with several round holes. Its flexure accommodates mounting misalignment. Miki Pulley calls this a membrane design.
CENTAX couplings are related to CENTAFLEX products and are used in generators, marine main engines, auxiliary engines, and similar applications.
Although CENTAX product information is not published as a dedicated section of the website, a brief introduction appears in the marine product lineup of the general catalog, available through the CENTAFLEX catalog download section.
See also “Pulley” and “Stepless Speed Changer.”
Miki Pulley is a comprehensive manufacturer of power transmission and control equipment, developing, manufacturing, and selling products such as shaft couplings, ETP BUSH friction locking devices, and electromagnetic clutches and brakes.
The company was founded as Miki Seisakusho in Kawasaki, Kanagawa Prefecture, in October 1939.
In 1954, it obtained a patent for a belt-type stepless speed changer and began manufacturing and selling it as the “Miki Pulley Stepless Speed Changer.” This product helped drive technological innovation in Japan and played an important role in subsequent industrial development.
In 1966, the company adopted the product name as its corporate name, becoming Miki Pulley Co., Ltd.
Its Chinese name is 三木普利株式会社.
It later expanded into couplings, electromagnetic clutches and brakes, DC motors, and inverters, continuing to support the driving power behind a wide range of machinery.
The current Miki Pulley logo symbolizes three concepts that express its products’ functions and performance: “Change Speed,” “Determine Position,” and “Transmit Rotation.”
See the videos “Miki Pulley Company Introduction” and “What Kind of Company Is Miki Pulley?”
English translation of image text
• Determine position
• Change speed
• Transmit rotation
The Miki Pulley logo was created to symbolize these three concepts.
See also “Moment of Inertia J: Calculation Formulas” and “Moment of Inertia J: Quick Reference Table.”
Moment of inertia indicates how easily or how reluctantly an object’s rotation changes.
A large moment of inertia also makes an object harder to stop.
For example, in machinery that repeatedly reverses direction, a large moment of inertia reduces the response during starting and stopping, affecting positioning accuracy.
Moment of inertia is expressed as the product of the rotating body’s mass M [kg] and the square of its radius R [m]. Multiplying moment of inertia by angular acceleration gives torque. Natural frequency can also be calculated from moment of inertia and torsional stiffness.
Moment of inertia therefore plays an important role in many areas, including machine accuracy and power calculations.
See also “Nominal Efficiencies of Premium Efficiency Motors.”
A motor converts electrical energy into rotational energy. Rotation is produced by attraction and repulsion between the north and south poles of electromagnets, formed by passing current through coils wound around iron cores.
The common three-phase motor is formally called a single-speed three-phase squirrel-cage induction motor.
Three-phase motors are said to account for more than 40% of worldwide electricity consumption, demonstrating how widely motors are used.
Reducing their energy consumption is therefore very important for energy conservation.
IEC and JIS standards define motor efficiency classes, or IE codes, and high-efficiency motors have come into use.
Starting with IE1 Standard Efficiency, classes progress through IE2 High Efficiency and IE3 Premium Efficiency. Super Premium Efficiency is also being considered.
IE stands for “International Energy-efficiency Class.”
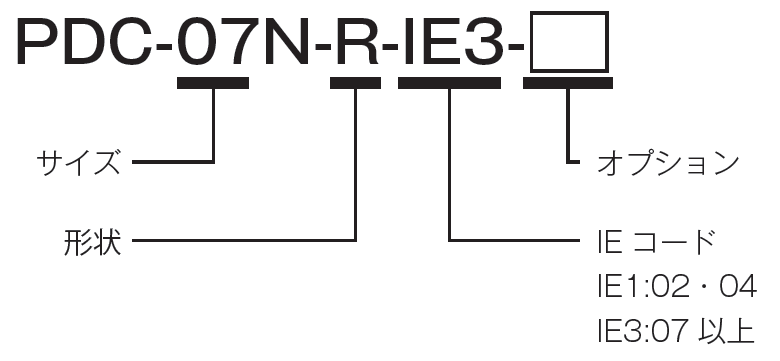
English translation of image text
Example model designation: PDC-07N-R-IE3-□
• Size
• Configuration
• IE code
IE1: Sizes 02 and 04
IE3: Size 07 and larger
• Options
N
See also “Resonance.”
Natural frequency is the characteristic resonant frequency of a structure. Every object has its own natural frequency.
When selecting a coupling, if the rotational excitation coincides with the natural frequency [Hz] of the mechanical system, such as a feed-screw system, resonance can produce vibration severe enough to damage the coupling. Vibration also spreads through the machine and reduces accuracy.
Calculating natural frequency in advance and avoiding operating speeds near it helps prevent resonance.
Natural frequency can be calculated from the torsional stiffness of the coupling and feed-screw system and the moments of inertia of the driving and driven sides.
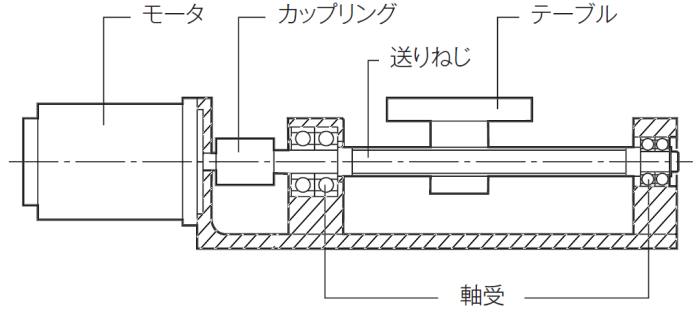
English translation of image text
• Motor
• Coupling
• Feed screw
• Table
• Bearing
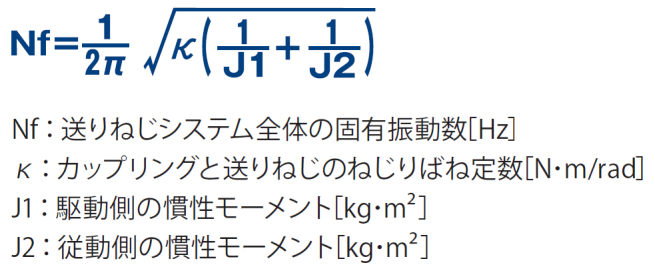
English translation of image text
Nf = (1 / 2π) × √[κ × (1/J1 + 1/J2)]
Nf: Natural frequency of the entire feed-screw system [Hz]
κ: Torsional stiffness of the coupling and feed screw [N·m/rad]
J1: Driving-side moment of inertia [kg·m²]
J2: Driven-side moment of inertia [kg·m²]
See also “CNC Lathe.”
An NC lathe automates cutting operations through numerical control, replacing work previously performed manually. An NC lathe that specifically uses a computer for numerical control is called a CNC lathe.
NC stands for “numerical control.” The term “NC machine tool” therefore covers numerically controlled machine tools generally, not just lathes.
A general term for metals other than iron. Aluminum, nickel, zinc, magnesium, gold, silver, and copper are nonferrous metals, so all Olympic medals are made of nonferrous metals.
A familiar distinction is magnetic attraction. Iron is attracted to magnets, while only a few other metals, including cobalt and nickel, show similar behavior.
What is the major difference between aluminum and stainless steel, both described here as nonferrous materials that are not attracted to magnets? It is their weight, or specific gravity.
Iron has a specific gravity of 7.8, as does stainless steel, whereas aluminum has a specific gravity of 2.7.
Miki Pulley therefore uses lightweight aluminum-alloy hubs in many couplings, including SERVOFLEX SFC, SERVOFLEX RUBBER, STARFLEX, SPRFLEX, and BELLOWSFLEX.
Reducing coupling mass reduces moment of inertia, improving machine response and enabling more precise control.
P
See also “ETP BUSH.”
When an incompressible fluid is enclosed in a sealed vessel, pressure applied at one point is transmitted undiminished to every other point. The fluid pressure is therefore equal throughout the vessel, regardless of its shape.
A common illustration is a U-shaped tube with different cross-sectional areas on the two sides. Suppose the left area is 1 and the right area is 5, with units omitted. Pushing the left piston down by 10 raises the right piston by 2. Applying a load of 3 on the left balances a load of 15 on the right. Displacement is inversely proportional to area, while supported load is directly proportional to area.
A hydraulic jack uses this principle, allowing human effort to lift a car.
The trade-off is a greater total movement, or more pumping strokes, on the input side.
Miki Pulley’s ETP BUSH friction locking devices also use Pascal’s principle. The sleeve portion contacting the shaft and hub forms a sealed chamber. Tightening a bolt pressurizes the medium inside, transmitting the same pressure throughout and uniformly loading the shaft and hub.
If the shaft or hub has a keyway or cutout where it contacts the sleeve, the sleeve may deform. Insufficient contact length can also cause deformation. As a basic design rule, the shaft and hub should support the full effective length of the sleeve. A deformed ETP BUSH may become impossible to remove.
A patent is an exclusive right granted after an invention—an industrially applicable idea expressed concretely in words or drawings—is filed with and examined by the Patent Office.
The patent system exists to support industrial development.
A television drama told the story of the inventor of instant noodles. A qualifying invention of something previously unavailable can give its inventor or employer exclusive rights, preventing others from making it without permission.
Because a perpetual monopoly would hinder industrial development, patent rights normally last 20 years from the filing date. After expiry, the invention enters the public domain and can be used by anyone.
Incidentally, the inventor of instant noodles did not seek to monopolize the invention through a patent. He wanted others to use the technology to make convenient, delicious noodles for Japan’s future.
Thanks to that decision, we can now enjoy many kinds of instant noodles from different companies. Patent applications are published 18 months after filing. Without publication, others might independently develop and file similar inventions. An earlier similar invention could then prevent the later application from receiving a patent, wasting time and expense and hindering industrial progress. The system therefore exchanges exclusive rights for public disclosure of the invention.
A patentable invention is also described as a technical idea utilizing a law of nature. An idea alone can include unrealistic concepts, which cannot all be monopolized. Industrial applicability is required, so a unique, one-off work such as a piece of art is not patentable on that basis. Merely finding something new is a discovery rather than an invention and is not itself patentable.
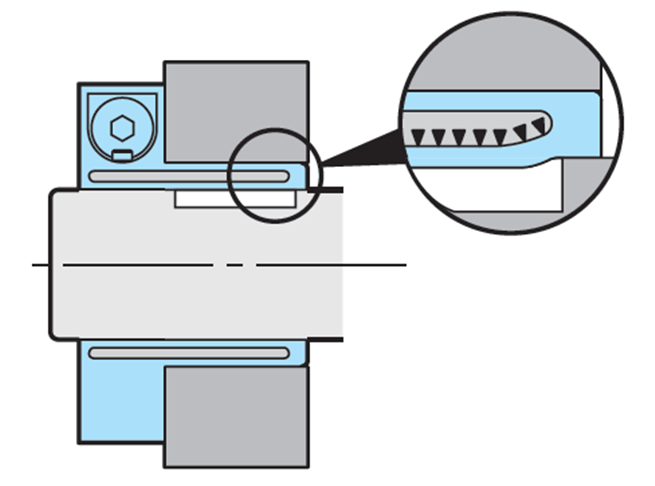
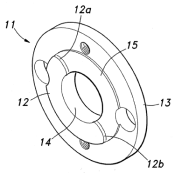
Miki Pulley holds patents relating to SERVOFLEX coupling structures and manufacturing methods. One example is the hub slit geometry shown, for which patents have been obtained in several countries.
Plating is a surface treatment that covers a metal or nonmetal material, such as ceramic, plastic, or glass, with a thin metallic film. Its purposes include corrosion protection and improved appearance.
Electroplating uses electric current to deposit metal ions on a surface. Electrodes are immersed in a solution containing dissolved metal ions; the ions deposit at the negative electrode, or cathode.
Electroplating / Electrolytic Plating
Electroplating uses electric current to deposit metal ions on a surface. Electrodes are immersed in a solution containing dissolved metal ions; the ions deposit at the negative electrode, or cathode.
Chemical Plating / Electroless Plating
Unlike electroplating, electroless plating does not use an external electric current. Electroplating requires a metal suitable for dissolution in the electrolyte, whereas chemical plating uses chemical reactions. Compared with electroplating, it may take longer and have coating-thickness limitations.
Electroless nickel plating offers uniform thickness, including on components with complex shapes.
Electroless Nickel Plating
Electroless nickel plating provides uniform coating thickness even on complex components. Miki Pulley uses it for ETP BUSH versions with basic corrosion protection, including ETP-E and ETP-T-C. The ETP BUSH sleeve is a critical part: pressure applied to the medium inside it produces the force securing the shaft and hub. Uneven plating thickness would prevent uniform pressure distribution and impair the specified allowable torque. Electroless nickel plating is therefore well suited because it offers corrosion protection and uniform thickness. It is also applied to pressure screws, whose threaded, uneven surfaces form a complex shape that benefits from a uniform coating.
The term refers to the part that drives a machine, such as a motor, pump, or engine.
“Mount the coupling on the prime-mover shaft” means, for example, “mount it on the motor shaft.”
See also “Miki Pulley.”
A pulley is a wheel over which a rope or belt runs. Traditionally, a pulley was installed above a well to guide the rope tied to a bucket and make lifting water easier. Such bucket wells are now uncommon.
The resemblance between this wheel and the variable-pitch pulleys used in belt-type stepless speed changers, together with the company’s rapid growth following its invention of the belt-type stepless speed changer, gave Miki Pulley its company name.
Pulling a rope over a pulley above a well feels easier than lifting the bucket directly. The required lifting force is unchanged with a fixed pulley, but the direction and posture are more convenient: standing and pulling downward is easier than leaning over the well and pulling upward.
How can the effort be reduced further? A motor could pull the rope or a pump could lift the water, but a simpler solution is to add a pulley in the right arrangement.
The pulley attached above the well is a fixed pulley. Add a movable pulley that travels up and down, and attach the bucket to it.
Pass the rope over the fixed pulley, around the underside of the movable pulley, and then secure the far end to the overhead structure.
Pulling the free end downward raises the bucket and movable pulley. The two rope segments support the load, halving the required pulling force, but also halving the bucket’s speed for the same rope-pulling speed.
Large mobile cranes use this principle of combining fixed and movable pulleys. When you next see one, observe how it moves and think of the well and pulley arrangement.
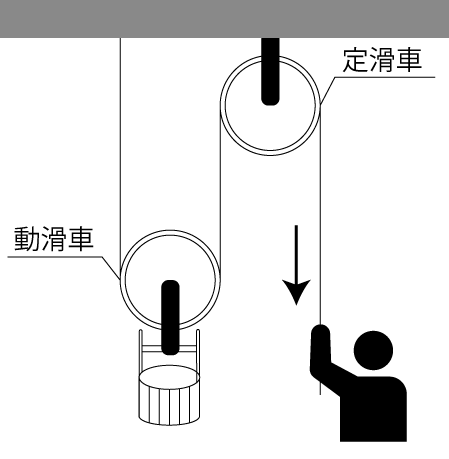
English translation of image text
• Fixed pulley
• Movable pulley
A pump uses pressure to draw in or move liquids or gases. A well pump is a familiar example.
The same principle is used in hot-water dispensers that dispense water when the top is pressed.
Q
Quenching and tempering is a heat treatment combining these two processes. “Quenched and tempered S45C” therefore means S45C steel that has undergone both treatments. This treatment increases the material’s hardness.
Miki Pulley uses materials equivalent to quenched and tempered S45C for the outer sleeves, outer rings, inner sleeves, inner rings, front taper rings, and rear taper rings of its POSI LOCK mechanical shaft locking devices.
R
“Radial” generally means radiating outward. Miki Pulley uses it for a direction perpendicular to the centerline of the shaft on which a coupling is mounted.
In CENTAFLEX couplings, bolts securing the rubber body or element perpendicular to the shaft centerline are called R-direction bolts, where R stands for radial.
Radial tires use the same sense of the word: their reinforcing cords are arranged transversely to the direction of rotation.
The corresponding direction parallel to the shaft is the axial direction.
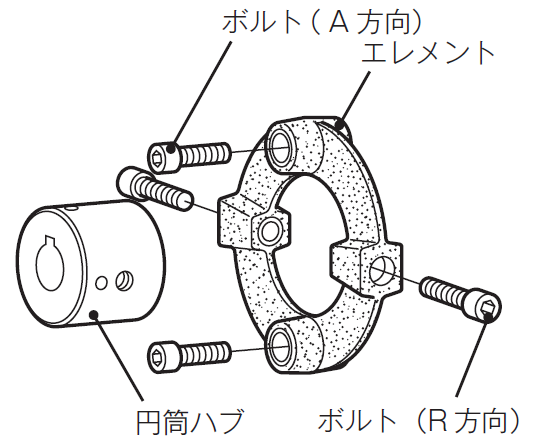
English translation of image text
• Bolt (axial / A direction)
• Element
• Cylindrical hub
• Bolt (radial / R direction)
See also “Torsional Stiffness.”
A radian is the unit of angle used in circular measure. In SI, it is the derived unit with a special name for plane angle.
You may think of angles in degrees: one revolution is 360°, and a right angle is 90°. This is not wrong, but it is not exact in the sense explained here. The number 360 resembles the 365 days in a year, and the division is said to have originated from an ancient approximation of a year as 360 days.
The degree system defines one degree as one three-hundred-and-sixtieth of a circle.
Circular measure instead defines angle through arc length, using the unit radian [rad].
On a circle of radius 1, an arc length of 1 subtends an angle of 1 radian. This gives a common definition with a clear geometrical basis.
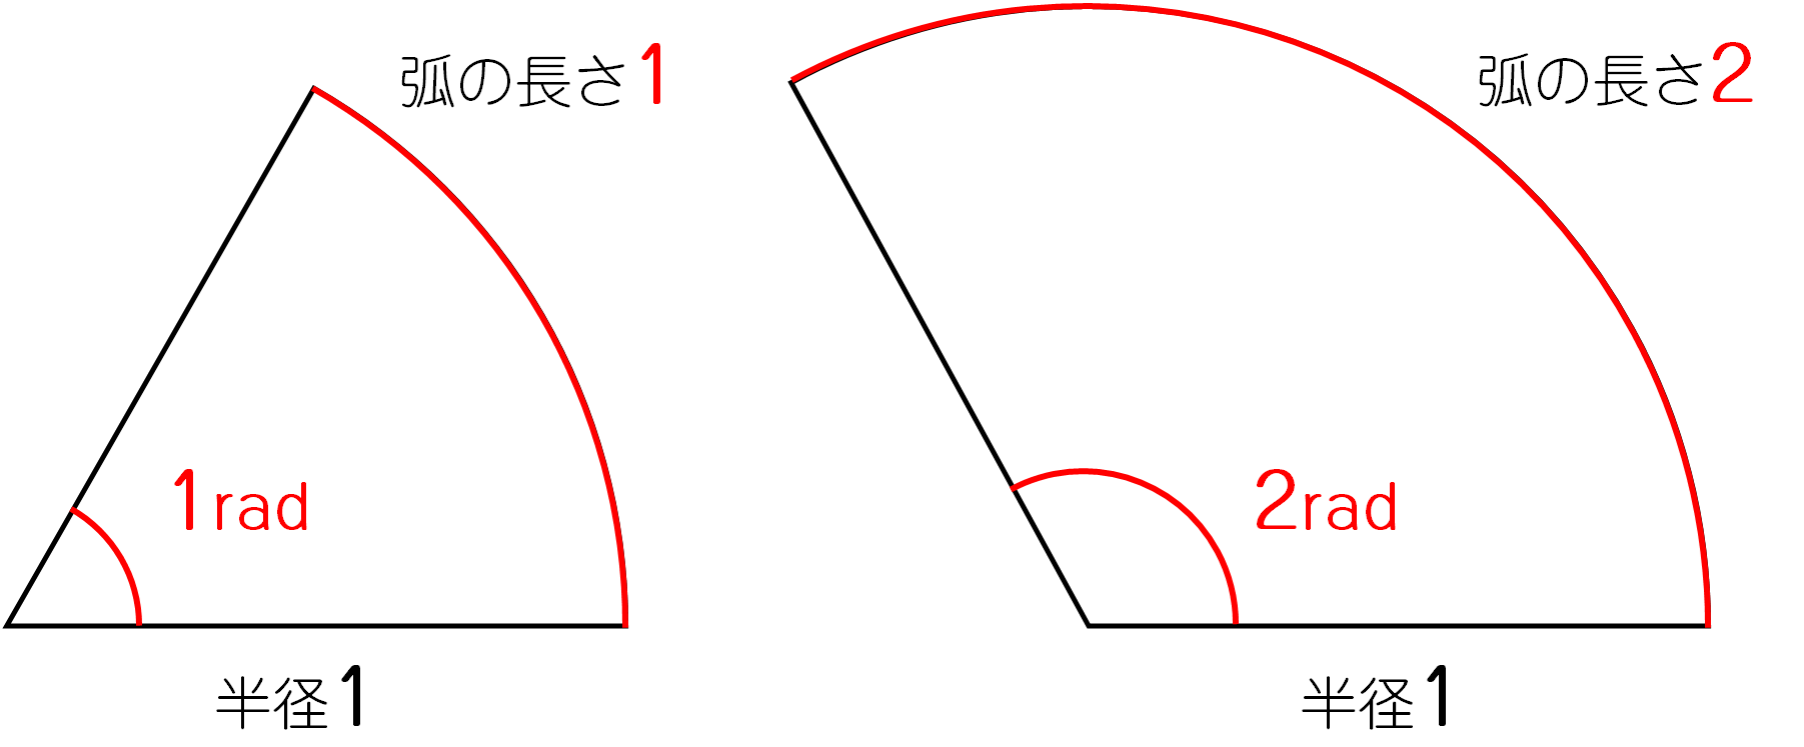
English translation of image text
Left: Arc length 1; radius 1; angle 1 rad
Right: Arc length 2; radius 1; angle 2 rad
Miki Pulley’s coupling specification tables list torsional stiffness, the ratio of applied twisting torque to angular deflection, in N·m/rad.
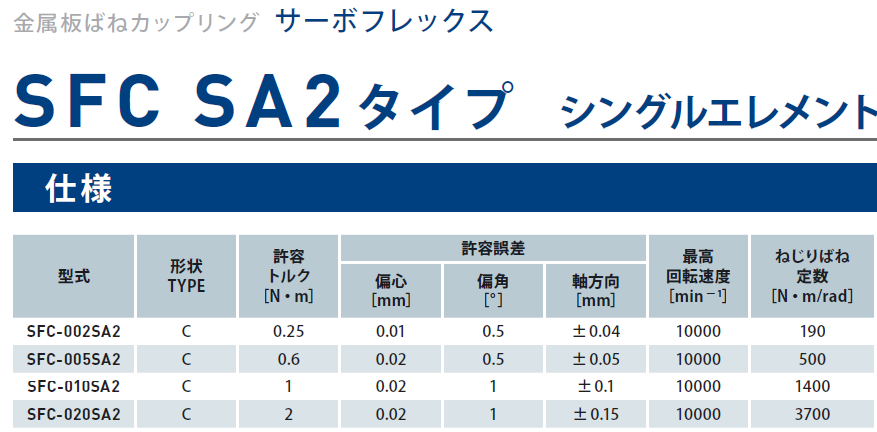
English translation of image text
Metal disc spring coupling — SERVOFLEX
SFC SA2 Type — Single Element
Specifications
Columns: Model | Configuration TYPE | Allowable torque [N·m] | Allowable misalignment: Parallel offset [mm] | Angular [°] | Axial [mm] | Maximum rotational speed [min⁻¹] | Torsional stiffness [N·m/rad]
SFC-002SA2 | C | 0.25 | 0.01 | 0.5 | ±0.04 | 10000 | 190
SFC-005SA2 | C | 0.6 | 0.02 | 0.5 | ±0.05 | 10000 | 500
SFC-010SA2 | C | 1 | 0.02 | 1 | ±0.1 | 10000 | 1400
SFC-020SA2 | C | 2 | 0.02 | 1 | ±0.15 | 10000 | 3700
What angle corresponds to the full circumference of a unit-radius circle? Circumference equals diameter multiplied by π, so it is 2π.
A full revolution therefore equals 2π radians.
The relationship between degrees and radians is:
360° = 2π rad
This is an important and useful conversion to remember.
Arc length can be found by multiplying radius by angle in radians.
Sector area can also be calculated readily from radius and arc length. Radians also simplify differentiation and integration, making circular measure useful in mathematics, physics, and mechanics.
“Rare metal” is a collective term for metals with limited production or availability, not the name of a single element like nickel or manganese. Approximately 50 metallic elements fall into this broad category.
In Japan, the term is used for scarce metals whose stable supply is important.
Low production may reflect natural scarcity or economic and technical difficulties in extraction. Some metals are concentrated in a single producing country, which may restrict supply. Political instability and continuing conflict in producing regions, including parts of Central and South America and Africa, can also affect availability.
Examples given include lithium, magnesium, chromium, cobalt, nickel, titanium, manganese, molybdenum, antimony, and tungsten. Within this category, 17 elements, including gold and silver, are called rare earths.
By contrast, metals produced in large quantities—iron, lead, zinc, copper, tin, and aluminum—are called base metals.
Japan imports most of both its base metals and rare metals, so securing stable supplies is a major issue.
In particular, 90% of rare metals are produced in China.
The issue extends beyond metals. According to the Agency for Natural Resources and Energy, Japan has a low energy self-sufficiency rate, ranking around 30th internationally, partly because of its limited land area.
Saudi Arabia and the United Arab Emirates together supply more than 50% of Japan’s crude oil imports, making supply interruption from those countries a serious concern.
Australia supplies more than 30% of Japan’s natural gas imports and more than 70% of its coal imports.
Japan therefore promotes resource conservation, recycling, and the development of alternative materials.
Its energy policy toward 2030 follows the basic concept of “3E + S”: Safety as the prerequisite, while simultaneously pursuing Energy Security, Economic Efficiency, and Environment.
For further information, see the Ministry of Economy, Trade and Industry website. Rare-metal resources are finite. Simply keeping this in mind may help us change wasteful everyday habits.
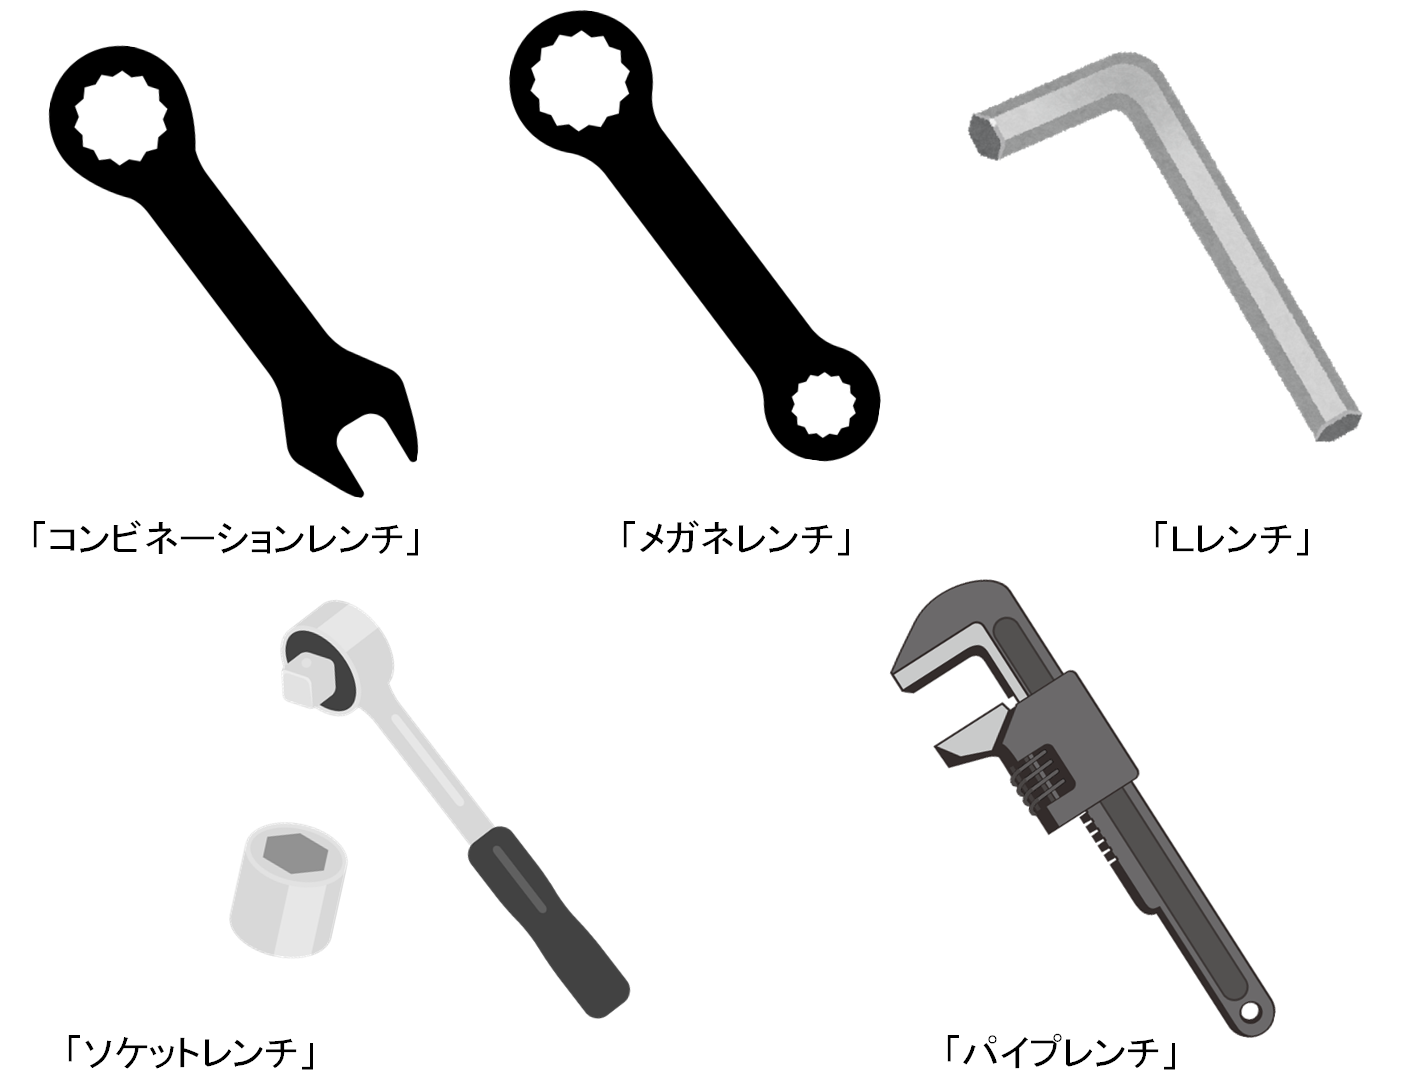
English translation of image text
• Combination wrench
• Ring spanner
• L-shaped hex key
• Socket wrench
• Pipe wrench
A resist is a material that reacts to light; industrially, the term refers to a material used to form a protective film.
The name comes from the English verb “resist.” The related word “résistance” is French.
Resists attracted attention in 2019 when Japan tightened its export control procedures for South Korea.
For example, semiconductor resist is applied to an integrated-circuit substrate, such as the familiar green board. Exposed areas harden while unexposed areas can be dissolved and removed, transferring a circuit pattern to the surface.
Light-sensitive resist used in semiconductor manufacturing is called photoresist, and Japanese technology holds a large share of the global market.
A semiconductor is a material with conductivity between that of a conductor and an insulator. Its resistivity changes with temperature, allowing electrical behavior to be controlled. Integrated circuits are made by combining transistors, capacitors, resistors, and other components on a semiconductor surface.
Because extremely small devices cannot be assembled by attaching separate parts, circuit patterns are instead formed on the semiconductor to provide equivalent functions.
Photoresist that hardens under light creates a protective film over the portions of the circuit pattern to be retained.
A similar technique is resist dyeing. Paste is brushed onto parts of a fabric pattern that must remain undyed. After dyeing, the paste is washed away to reveal the pattern. Semiconductor resist performs a comparable protective role.
In Miki Pulley products, resist is used in items such as control panels for DC motors.
Although resist appears on export control lists, the relevant Miki Pulley products do not meet the controlled technical thresholds and are classified as non-listed in their export control classification certificates.
See also “Natural Frequency.”
Resonance is the phenomenon in which vibration amplitude increases when an external vibration matches an object’s natural frequency. The term is used for both electrical and mechanical systems.
Examples include a washing machine shaking heavily during its spin cycle and a bridge swaying significantly in the wind. In electrical control systems, resonance caused by servo motor gain settings is also called oscillation.
Resonance can create severe vibration throughout a machine and cause serious problems. To prevent it, determine the natural frequency of the complete mechanical system and adjust excitation frequencies or rotational speeds so they do not coincide with it.
The torsional stiffness of the mechanical system and the coupling, as well as damping, influence vibration behavior. Changing the coupling is therefore one possible remedy. This is why Miki Pulley’s coupling specification tables include torsional stiffness.
See the videos “Reducing Servo Motor Vibration at High Gain” and “Reducing Stepping Motor Vibration at Resonance.”
These videos show how vibration from high servo gain or stepper motor pulsation at resonance can be reduced by replacing metal couplings, such as SERVOFLEX or HELICAL, with SERVOFLEX RUBBER couplings that use high-damping laminated rubber elements.
See also “Snap Rings: Standards and Dimensions (C-Type Retaining Rings / C-Rings / Retaining Rings / Stop Rings).”
A retaining ring is a ring-shaped spring fitted into a groove in a shaft or bore to prevent axial movement.
It belongs to the family of springs, as is clear when fitting it: it must be expanded or compressed. This can be difficult, and rings can easily spring away during installation.
Types include C-type retaining rings, E-type retaining rings, and grip rings. C-type rings are common and are divided into shaft and bore types, each with eccentric and concentric versions. This gives four combinations, such as an eccentric C-type shaft ring and a concentric C-type bore ring.
C-type rings are used in grooves, while E-type and grip rings are used on shafts without grooves.
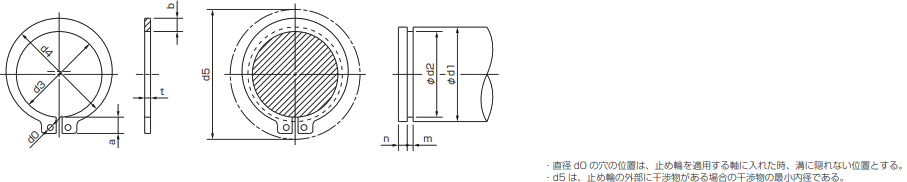
English translation of image text
• The holes of diameter d0 must be positioned so that they do not open into the groove when the retaining ring is fitted to the applicable shaft.
• d5 is the minimum inside diameter of an obstruction outside the retaining ring.
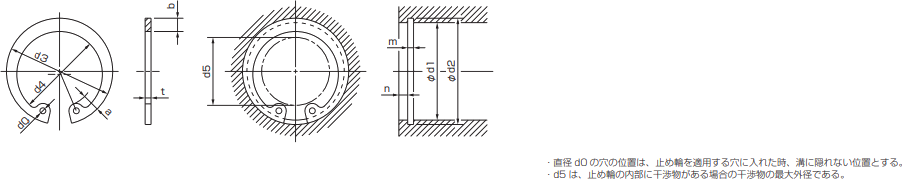
English translation of image text
• The holes of diameter d0 must be positioned so that they do not open into the groove when the retaining ring is fitted into the applicable bore.
• d5 is the maximum outside diameter of an obstruction inside the retaining ring.
Special retaining-ring pliers are needed to expand or compress rings during installation and removal. Ordinary pliers, such as long-nose pliers, are generally unsuitable. Ordinary pliers close their tips when the handles are squeezed, while external retaining-ring pliers must spread their tips.
JIS uses “retaining ring,” but other names have long been used. “Stop ring” refers to preventing movement; “snap ring” refers to the snapping sound during installation.
A C-type retaining ring is also called a circlip.
Similar-sounding Japanese terms include “snap endo” and “snack endo,” both meaning the same variety of pea introduced from the United States in the 1970s. The alternative “snack” name arose from its association with convenient snack foods, but Japan’s Ministry of Agriculture, Forestry and Fisheries standardized the name as “snap endo.”
“Snap” conveys breaking crisply or making a sharp snapping sound.
Unlike a flexible coupling, a rigid coupling has no element to accommodate misalignment between the two shafts.
Miki Pulley supplies SERVORIGID as its rigid coupling range.
With no flexible section, a rigid coupling can transmit high torque and offers very high torsional stiffness. Compared with a flexible coupling transmitting the same torque, its outside diameter can be smaller, reducing moment of inertia.
The two shafts must, however, be aligned as accurately as possible.
Although most Miki Pulley couplings are flexible, SERVORIGID rigid couplings are also available to suit different applications. Consider the benefits of each type and select the best coupling for the intended use.
RoHS is the directive restricting the use of certain hazardous substances. It is a revision effective July 1, 2006, of the first directive that entered into force in Europe in February 2003. Its purpose is to restrict hazardous substances in electrical and electronic equipment placed on the EU market to permitted concentrations, thereby preventing chemicals harmful to people and the environment from being released into nature.
The directive initially prohibited, in principle, six substances: lead, mercury, cadmium, hexavalent chromium, polybrominated biphenyls (PBB), and polybrominated diphenyl ethers (PBDE).
Although RoHS is European legislation, it also affects products imported into Europe, so Japanese suppliers must meet the requirements as well.
The revised RoHS Directive (RoHS 2) entered into force on July 21, 2011. Four phthalates were added on June 4, 2015, bringing the number of restricted substances to ten: bis(2-ethylhexyl) phthalate (DEHP), butyl benzyl phthalate (BBP), dibutyl phthalate (DBP), and diisobutyl phthalate (DIBP). Their concentration restrictions took effect on July 22, 2019. The scope also expands to medical and control equipment.
Miki Pulley promotes the supply of products free of restricted substances and identifies RoHS-compliant products with marks on its website and in its catalogs.
RoHS compliance certificates can be downloaded from our website.
See “Download RoHS Compliance Certificates.”
English translation of image text
RoHS-compliant products

S
See “Service Factor.”
A SCARA robot is an industrial robot whose arm moves horizontally. SCARA stands for “Selective Compliance Assembly Robot Arm.”
Its basic motions comprise three rotary movements and one vertical movement. Because the rotary joints are arranged for motion in a horizontal plane, the robot is stiff vertically and compliant horizontally, making it suitable for tasks such as inserting components.
See also “Torque.”
In simple terms, it is a reference value divided by the maximum value anticipated in design.
For example, if the reference is a failure torque of 100 N·m and the maximum allowable design torque is 50 N·m, the service factor, or safety factor in this example, is 2. If 50 N·m is listed as the allowable torque in the catalog, a twofold margin remains before failure. A safety factor of 1 would mean the product fails at the allowable torque.
For STARFLEX couplings, calculate the actual applied torque Ta, then multiply it by the service factors—called correction factors here—specified for the operating conditions to obtain corrected torque Td.
Select a size so that Td does not exceed the STARFLEX rated torque Tn.
STARFLEX also has a maximum torque Tm set at twice its rated torque. A further safety margin above that maximum determines the torque at which the coupling fails.
Unexpected events such as impact can generate much larger torques, so sufficient safety margins are provided to prevent failure under such conditions. Safety factors are thus considered at several stages to support reliable use.
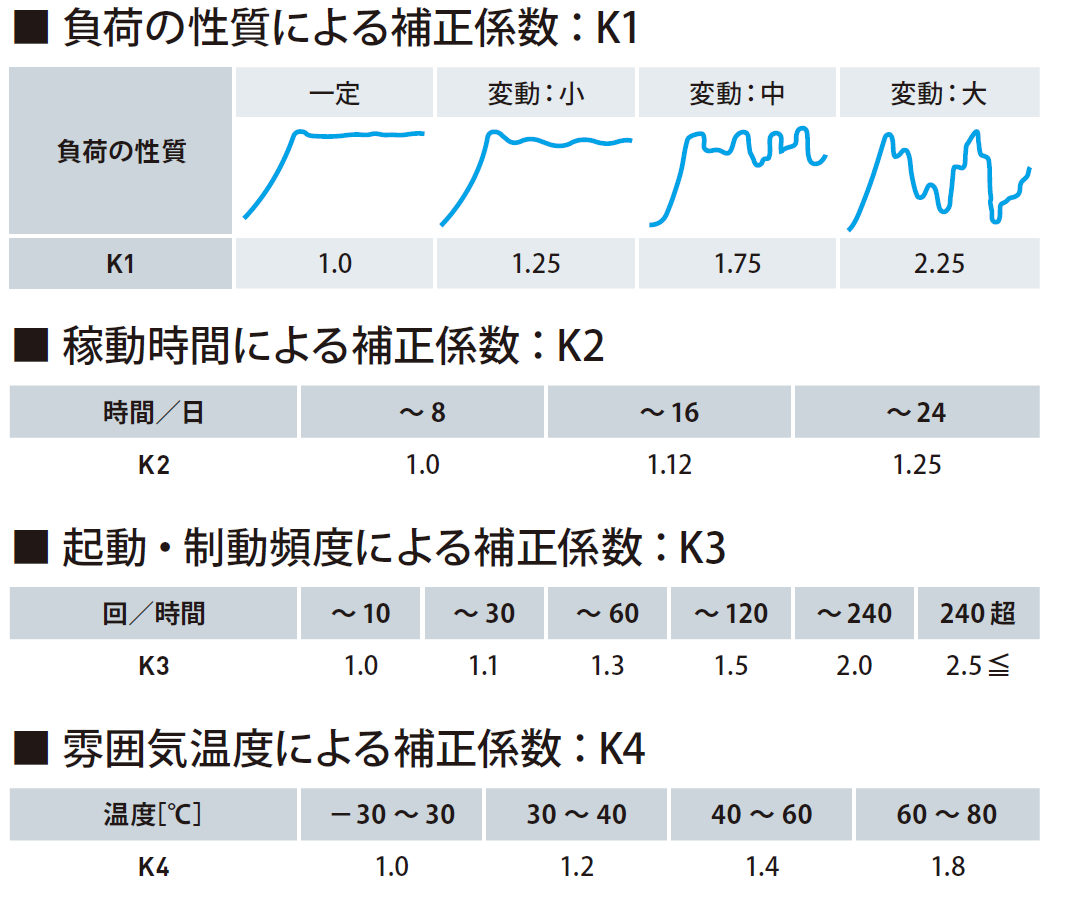
English translation of image text
Correction factor for load characteristics: K1
Load characteristics: Constant | Small fluctuations | Medium fluctuations | Large fluctuations
K1: 1.0 | 1.25 | 1.75 | 2.25
Correction factor for operating time: K2
Operating hours per day: Up to 8 | Up to 16 | Up to 24
K2: 1.0 | 1.12 | 1.25
Correction factor for starting and braking frequency: K3
Operations per hour: Up to 10 | Up to 30 | Up to 60 | Up to 120 | Up to 240 | More than 240
K3: 1.0 | 1.1 | 1.3 | 1.5 | 2.0 | 2.5 or greater
Correction factor for ambient temperature: K4
Temperature [°C]: −30 to 30 | 30 to 40 | 40 to 60 | 60 to 80
K4: 1.0 | 1.2 | 1.4 | 1.8
A servo motor allows control of speed, position, and torque. A detector, such as a rotary encoder, and a servo driver or amplifier are required for control.
Detailed explanations of servo motor construction and control are available from major motor manufacturers, so only a brief overview is given here.
An ordinary general-purpose motor simply rotates at a substantially constant speed. Adding an inverter allows its speed to be changed by varying frequency.
DC servo motors subsequently enabled more precise positioning and speed control. However, they require brushes, a characteristic of DC motors, and these wear over time.
Brushless, maintenance-free AC servo motors were developed to address this. They control torque by varying the magnitude of the sinusoidal current.
SERVOFLEX is Miki Pulley’s product name for its metal disc spring couplings.
Developed for high-speed, high-precision positioning and ultra-precise control with servo motors and similar equipment, these couplings combine high rigidity, high torque, low inertia, and fast response. They remain flexible in angular, parallel-offset, and axial directions and have completely zero backlash.
SFC, SFS, SFF, SFM, and SFH models are available with different allowable torques, stiffnesses, and other characteristics.
The basic structure sandwiches disc spring elements between two hubs. Specifications vary with the number, shape, and arrangement of the spring plates, including single- and double-element configurations.
Because stiffness is very high, permissible misalignment is relatively small. Adding a spacer between the hubs and disc springs increases the misalignment that can be accommodated.
See “Rigid Coupling.”
See “Coupling.”
This treatment applies a paint-like solid lubricant to form a coating. Solid lubricants reduce friction and wear and improve lubrication where oil cannot be used.
Miki Pulley uses this treatment on clamping bolts for SERVOFLEX SFC couplings and on the clamping bolts of stainless-steel F-type POSI LOCK PSL-K mechanical shaft locking devices.
Lubricant is commonly applied to bolt threads before tightening. However, different lubricant compositions can change the coefficient of friction, causing variations in the tightening result. Excessive axial force may damage the clamping bolt or coupling.
If lubricant enters between the coupling and shaft, it may also cause slipping and reduce transmissible torque.
A solid lubricant coating therefore helps maintain consistent tightening characteristics and prevents lubricant migration. It is also suitable for bolts because large quantities can be treated easily.
See also “Wrench.”
A spanner is a tool with an opening at one end, or openings of different sizes at both ends, for turning nuts and bolts. “Spanner” is British English and can refer broadly to tools for turning nuts and bolts.
The open-end shape described here is suited to hexagonal heads.
It cannot turn a socket head cap screw with a round outer head. A hex key, also called an L-shaped hex wrench, turns the hexagonal socket in such a screw. “Wrench” is the American English term.
JIS calls a hex key a “hexagon bar spanner.”
A spigot joint uses a projection on one component and a matching recess on the mating component to simplify concentric positioning during assembly.
Miki Pulley recommends spigot mounting where accurate positioning is needed, including alignment of the two shafts connected by a coupling and positioning the brake mounting surface relative to the shaft in electromagnetic clutch/brake installations.
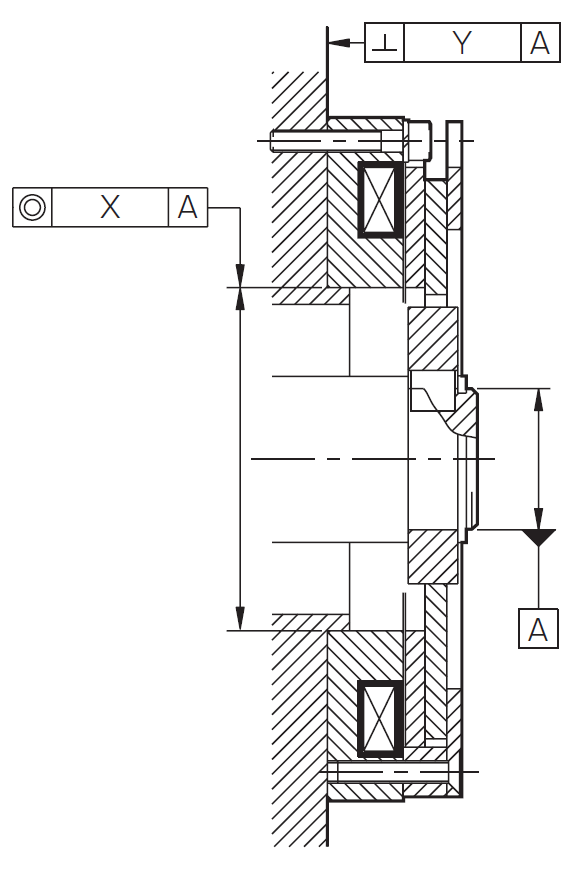
See also “Involute Curve.”
A spline connection uses multiple gear-like grooves machined in a shaft and mating hub to transmit high torque. If the tooth profile follows an involute curve, it is called an involute spline.
Splined connections are commonly used for shafts and hubs with the CENTALOCK mechanism in CENTAFLEX couplings.
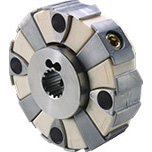
See also “CENTAFLEX.”
A spring pin is formed by rolling an elastic sheet into a cylindrical shape.
It is driven into a hole and uses its radial spring action to connect adjacent components.
CENTAFLEX CF-A and CF-H models use spring pins to connect the cylindrical and flange hubs to the rubber body or inserts. Pins driven into the hub holes prevent the rubber body or inserts from twisting as the bolts are tightened.
Without them, the rubber may be secured in a twisted condition and fail prematurely at that point. Small sizes experience little twisting and therefore do not require spring pins.
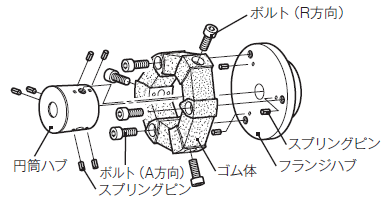
English translation of image text
• Bolt (radial / R direction)
• Spring pin
• Flange hub
• Rubber body
• Bolt (axial / A direction)
• Cylindrical hub
“Spring pin” appears at both indicated connection locations.
See also “Idler.”
A sprocket is a toothed wheel used for chain transmission. A gear generally meshes with another gear; a sprocket meshes with a chain to transmit power.
Chains and belts stretch slightly during use. A tensioner removes the resulting slack.
Miki Pulley’s ROSTA tensioners are available with sprocket idlers that automatically compensate for slack in chain drives.
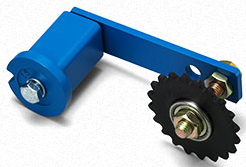
The international definition describes stainless steel as an alloy with iron as its main constituent—at least 50%—and at least 10.5% chromium.
JIS uses the material designation “SUS,” which derives from “Steel Special Use Stainless.” SUS is therefore not a universally recognized international designation.
The Japan Stainless Steel Association’s website provides comparison tables with ISO and other standards.
Adding chromium to iron causes chromium to react with oxygen and form a thin protective surface film. This passive film inhibits rust.
Although thin, it is strong and regenerates automatically after damage if oxygen is present.
One of the most widely used grades is SUS304, which contains at least 18% chromium and is also called 18-chromium stainless steel.
It offers resistance to rust, acids, and corrosion.
Miki Pulley uses SUS304 in SERVOFLEX coupling elements, 3000-model HELICAL couplings—marked as equivalent to SUS304—and sleeves for stainless-steel F-type POSI LOCK PSL-K devices.
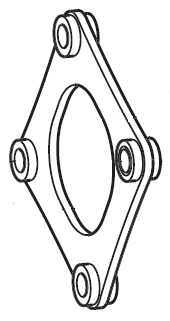
JIS Z 8002 defines standardization as establishing provisions for common and repeated use to achieve an optimum degree of order in a given context, addressing actual or potential problems.
In simple terms, if work varies from person to person, an organization may seek to eliminate that variation and improve efficiency by creating a work manual and ensuring everyone follows it. This standardizes the work.
For example, inconsistent drawings may lead a machinist to finish a part to the wrong dimensions. This can happen when machining dimensions are unclear or must be calculated from other dimensions.
Clearly dimensioning features from a defined datum enables anyone to machine them correctly. A drawing manual should therefore ensure the same result regardless of who prepares the drawing.
Even a simple rule—always dimension machined features clearly from the machining datum—can prevent mistakes and save time. It helps machinists, drawing authors, and inspectors and ultimately provides customers with products of consistent quality.
Remember the principle of achieving the greatest effect with the least necessary work.
Once a manual has been created, it can be reused, although periodic review is necessary. Time spent arguing that writing a manual is wasteful would be better spent creating it.
At the same time, make the manual visible and readily accessible so anyone can consult it whenever needed. Otherwise, its value will be lost.
See also “Pulley” and “Miki Pulley.”
A stepless speed changer varies speed continuously, without fixed steps.
A three-speed bicycle, by contrast, has a stepped transmission with three distinct ratios.
Miki Pulley offers various forms of continuously variable speed control: belt-type stepless speed changers using pulleys and belts, mechanical types such as Zero-Max stepless speed changers, and electrical systems such as DC motors and inverters.
English translation of image text
RoHS-compliant products
A stepping motor rotates in fixed angular increments, like climbing a staircase one step at a time. This is the origin of its name. It is also called a pulse motor because it rotates when current pulses are applied in sequence.
A pulse is a short event, like a heartbeat. A signal that repeatedly switches on and off at regular intervals is called a pulse signal and is represented by a rectangular waveform.
Because operation consists of repeated on/off steps, rotation can be described, in an exaggerated sense, as jerky. The reason lies in the motor’s construction. It has a rotor and stator, with iron cores spaced evenly around the stator’s circumference. Coils are wound around the cores.
Sequentially energizing the coils magnetizes the cores and draws the rotor around. Reversing the sequence reverses rotation.
A circuit is needed to generate pulses at a set frequency and apply current to the stator coils in sequence. Unlike a DC motor, a stepping motor does not simply rotate when a voltage is applied.
The circuit also allows different pulse signals to be used, enabling various forms of control. Changing the pulse repetition frequency changes rotational speed. Each pulse corresponds to a fixed rotation angle, so changing the pulse count changes the angular position.
Thus, speed is controlled by pulse frequency and angle by pulse count. Combining the two enables varied motion control. Reversing the coil energization sequence changes direction, while maintaining current can hold the rotor in position.
Whereas servo motors use closed-loop control, stepping motors are described here as using open-loop control. They do not require servo-style feedback, making control very simple.
Their output power is generally lower than that of servo motors, so they are often used in home appliances and office equipment, such as printer paper-feed mechanisms.
See also “Tensile Strength.”
Strain is the change in a material’s length under tensile force divided by its original length. The change is the stretched length minus the original length. This value is expressed as a percentage.
Materials can experience forces other than tension, but tension is used here for clarity.
A strain gauge is a sensor attached to a structure to measure how much it strains when force is applied.
Why measure strain? As tensile force increases, a material passes from its elastic region into a plastic region, where permanent deformation occurs, and eventually fractures. It is important to determine the force that will deform or break a structure.
A strain gauge converts strain into an electrical signal, allowing numerical monitoring and control to help prevent deformation and failure.
While strain describes the relative dimensional change, the force also produces internal stress, or force per unit area.
In the elastic range, Hooke’s law gives:
Stress = Strain × Young’s modulus
Types of strain include tensile, compressive, elastic, plastic, and shear strain, depending on how the load is applied and the resulting behavior.
Strain also has longitudinal and transverse components. Pulling a material stretches it in the load direction and makes it narrower perpendicular to that direction.
These are longitudinal and transverse strain, and their ratio is associated with Poisson’s ratio.
The Japanese character 歪み can be read as either “hizumi” or “yugami.” Their basic meanings overlap, but their usage differs.
“Hizumi” appears in expressions for audio distortion or social strain. The character combines elements meaning “not” and “correct,” suggesting departure from a normal condition.
“Yugami” is used for distortion of a face or personality. My personal impression is that “hizumi” emphasizes a deviation from the original state, while “yugami” emphasizes the deformed shape itself.
In mechanics, the technical term is “hizumi,” translated as strain.
T
See also “Yield Point” and “Strain.”
JIS Z 2241, “Metallic Materials—Tensile Testing,” defines tensile strength as the stress corresponding to the maximum test force. Stress is the test force at any point during the test divided by the specimen’s original cross-sectional area, before stretching.
JIS G 0202, “Glossary of Terms Used in Iron and Steel (Testing),” similarly defines it as the maximum tensile load sustained in a tensile test divided by the original cross-sectional area of the specimen’s parallel portion.
Test conditions and specimen dimensions are specified. The illustration shows the specimen after fracture.
Tensile strength may sound like a tensile load, but it is a stress, not a load.
Steel gradually elongates under tension. Up to approximately the yield point shown, it returns to its original shape when the load is removed; this is the elastic region. Beyond that, it enters the plastic region and retains permanent deformation. Further stretching leads to cracking and ultimately fracture.
Plotting test results as stress against strain—elongation divided by original length, expressed as a percentage—produces a stress–strain diagram. Some materials do not show the distinct yield point illustrated. Cast iron, which elongates little, and stainless steel, which elongates considerably, do not necessarily follow this particular curve.
The maximum stress on the curve, marked by the red circle, is the tensile strength. The curve then falls until fracture occurs.
When developing or designing products, selecting a material with adequate strength is essential. Tensile strength is an important mechanical property indicating the maximum engineering tensile stress a material can withstand before progressing toward failure.
English translation of image text
• Stress
• Strain
• Yield point
• Tensile strength
• Fracture point
“Thrust” means a pushing force. In Miki Pulley terminology, thrust force acts along the shaft, parallel to its axis.
ETP BUSH specifications include an allowable thrust force, meaning force acting in the same direction as the shaft on which the ETP BUSH is installed. The direction perpendicular to the shaft is called radial.
In coupling specifications, Miki Pulley uses “axial” for the direction of permissible displacement along the shaft. The terms thrust and axial are closely related; axial emphasizes the shaft centerline, while thrust emphasizes the direction of the force. “Axial” is therefore used for couplings connecting two shafts.
ETP BUSH specifications include both allowable thrust force and allowable radial load. Radial load is easy to visualize: when a pulley or sprocket is secured with an ETP BUSH, a belt or chain applies force perpendicular to the shaft.
Why is an allowable thrust force also specified? Consider a rotary table secured with an ETP BUSH. A horizontally oriented table on a vertical shaft would slip downward if unsecured. Supporting it applies a downward force to the ETP BUSH. This force is parallel to the shaft and is therefore thrust, so allowable thrust force must also be considered.
See “Torque Wrench.”
See also “Service Factor.”
Torque is the product of a force tending to rotate an object and the distance from the center of rotation to where that force acts. In other words, torque = force × moment arm, measured in N·m.
For a coupling, its torque specification describes the torque it can transmit, rather than simply the torque needed to rotate the coupling itself.
Miki Pulley’s coupling specifications use “allowable torque” or both “rated torque” and “maximum torque.”
Allowable torque is the upper value for normal use. It is specified for relatively stiff couplings such as SERVOFLEX, SERVORIGID, BAUMANNFLEX, and SCHMIDT.
HELICAL, SPRFLEX, and BELLOWSFLEX couplings specify both rated torque and maximum torque. Normal operation should remain within rated torque. Impact or vibration may occasionally raise the applied torque; maximum torque describes the temporary level permitted in such cases, generally only a few times per day.
These torque limits may be reduced by conditions such as coupling bore diameter and operating speed. Specifications differ by coupling, so confirm the actual operating conditions and select appropriately.
See “Torque Wrench.”
The same explanation also applies to “Torque Driver.”
A torque wrench is a tool for tightening bolts and screws to a specified torque. Hand feel alone cannot reliably achieve the torque specified for a nominal size such as M8.
Specified tightening torque produces the required bolt tension. The resulting clamping action holds the joint securely and prevents loosening.
Insufficient tightening allows the bolt to loosen during use. A loose bolt can be thrown from a rotating product and cause a serious accident.
Excessive tightening can damage the threads, reducing their ability to maintain tension and ultimately also causing loosening. Both undertightening and overtightening are therefore problematic; fasteners must be tightened to the specified torque.
Poor control of coupling bolt and screw tightening torque is one possible cause of coupling failure.
Torque wrenches are effective for relatively high tightening torques on socket head cap screws and hexagon head bolts. Torque drivers are used similarly to ordinary screwdrivers and are suitable for lower torques, such as those required for hexagon socket set screws.
Use the appropriate interchangeable head or attachment for the fastener shape.
For torque wrenches and drivers suitable for each product size, see the SERVOFLEX, ETP BUSH, or POSI LOCK catalog.
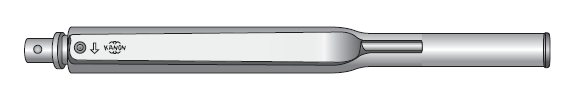
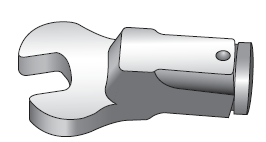
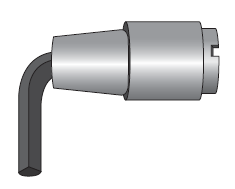
Torsional stiffness describes a coupling’s resistance to twisting. It is expressed as the applied torque divided by the resulting angular deflection, in N·m/rad.
A coupling with high torsional stiffness transmits force and motion from the input shaft to the output shaft with little torsional deformation.
In a printing machine, for example, this reduces registration errors and improves precision.
Compare two servo-compatible couplings with the same 44 mm outside diameter: SERVOFLEX SFC-040SA2 has a torsional stiffness of 20,000 N·m/rad, while SERVOFLEX RUBBER SFR-040SA1 has 1,128 N·m/rad—roughly a twentyfold difference. This illustrates SERVOFLEX’s high rigidity and responsiveness.
STEPFLEX’s strengths are high damping and low reaction force. These characteristics rapidly reduce vibration and help avoid resonance over a wide operating-speed range.
Miki Pulley offers many types of coupling so that the most suitable one can be selected for each application.
Coupling specification tables normally list static torsional stiffness, or simply torsional stiffness. CENTAFLEX CF-A, CF-H, and CM models instead list dynamic torsional stiffness.
Static torsional stiffness describes the force–deflection relationship when load is applied slowly; dynamic torsional stiffness describes it when load is applied at a given rate.
For metals, the difference is generally small. For rubber and resin couplings, dynamic stiffness tends to exceed static stiffness. Dynamic values are therefore listed to better reflect actual operating conditions.
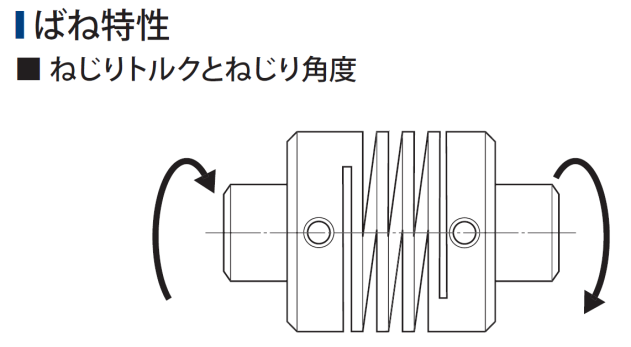
English translation of image text
• Spring characteristics
• Torsional torque and torsional angle
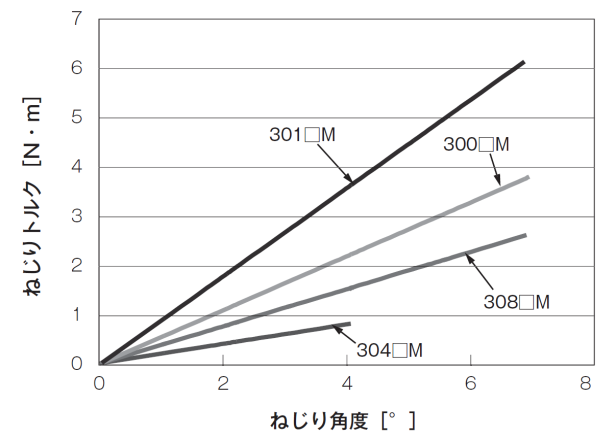
English translation of image text
Vertical axis: Torsional torque [N·m]
Horizontal axis: Torsional angle [°]
Model labels, unchanged: 301□M, 300□M, 308□M, 304□M
U
See also “International System of Units.”
A prefix is a symbol placed before a unit to make the magnitude easier to express. For example, 1 mm is one millimeter, in which “milli” is the prefix. In 1 km, one kilometer, “kilo” is the prefix. Both use the meter, a unit of length and one of the SI base units.
Thus, “milli” is not itself a unit, even though Japanese speakers sometimes informally read “mm” simply as “milli.” Likewise, “kilo” alone does not identify a quantity: it can be used in kilometers, kilograms, kilowatts, and other units.
For length, familiar prefixes include micro, milli, centi, and kilo. They allow compact expressions such as 1 m = 100 cm and 1,000 m = 1 km.
Even without the unit, “kilo” suggests a factor of 1,000.
Similarly, familiar data-capacity terms such as giga and tera help us picture the size of a three-terabyte storage device. Common prefixes progress in factors of 10³: kilo = 10³, mega = 10⁶, giga = 10⁹, and tera = 10¹².
Consider rainfall. Reports in Japanese often say that “50 milli of rain” is expected, but “milli” is only a prefix.
What is the actual unit? Rainfall is expressed in millimeters because it measures a height or depth.
A rain gauge explains why. A storage rain gauge measures water collected in a graduated cylinder. Another type is the tipping-bucket gauge. Storage gauges require someone to read them, while tipping-bucket gauges can operate unattended and are now more common.
One millimeter of rain means a water depth of 1 mm over an area of 1 m², or 1 m × 1 m. That is one liter of water.
Rainfall is often reported per hour, but daily totals or ten-minute totals are also used according to the situation.
Japan Meteorological Agency data give Tokyo’s highest daily rainfall as 371.9 mm in 1958 and highest hourly rainfall as 88.7 mm in 1939.
At 30 mm per hour, the risk of disaster rises sharply and the rain can seem to pour as though from an overturned bucket. This shows how intense 88.7 mm in an hour would be. Thirty millimeters should not be dismissed as “only three centimeters.”
Although it may feel as though severe rain is a recent phenomenon, these older records show that damaging rain can occur at any time. Keep that possibility in mind.
V
A varistor is an electronic component that suppresses the reverse voltage generated when current to an electromagnetic coil is interrupted. Miki Pulley calls it a varistor or protective element.
The similar-sounding “barista,” meaning someone who prepares espresso, is an Italian word and unrelated.
The coils in electromagnetic clutches and brakes resist changes in current. When the circuit is opened, the energy stored in the coil produces a large reverse voltage, or back electromotive force.
This can damage semiconductor components in the control circuit, degrade coil insulation, shorten relay life, weld relay contacts, and cause electrical noise in wiring.
Connecting a varistor in parallel with the coil absorbs the voltage surge. Select its rating to match the coil voltage and the model and size of Miki Pulley’s electromagnetic clutch or brake.
The catalogs list recommended clutch/brake power supplies—some with built-in varistors—and suitable varistors for each model and size. Use the specified compatible varistor.
W
The Web is one of the systems that uses the Internet to transfer data. The term comes from the final word of “World Wide Web.”
The “www” in Miki Pulley’s website URL, https://www.mikipulley.co.jp, stands for World Wide Web.
See also “Spanner” and “Hexagon Bar Spanners (Hex Keys / L-Shaped Wrenches / Hexagon Wrenches): Shapes and Dimensions.”
A wrench is a tool for turning nuts and bolts. “Wrench” is American English, while “spanner” is the corresponding British English term.
Both words are used in Japan, though “wrench” appears more frequently in product names.
One particularly relevant tool for Miki Pulley products is the torque wrench. At least around me, nobody calls it a torque spanner. That is how well established the term “torque wrench” has become.
JIS calls a hex key a “hexagon bar spanner,” yet the common Japanese names are “hex wrench” or “L wrench.” The latter is easy to remember because of the tool’s L shape.
Because wrench and spanner essentially differ by American and British usage, their coexistence in Japanese is understandable.
The combined term “spanner wrench” is also used. These tools have wrench or spanner ends on both sides, broadly including ring spanners and combination wrenches. Some tools have hooks that engage grooves for turning, and many other shapes exist.
As tools for turning nuts and bolts developed for different applications, many types of wrench emerged, including box wrenches, adjustable wrenches, torque wrenches, pipe wrenches, socket wrenches, ratchet wrenches, ring spanners, combination wrenches, impact wrenches, and cross or four-way lug wrenches.
Y
See also “Strain” and “Tensile Strength.”
JIS G 0202, “Glossary of Terms Used in Iron and Steel (Testing),” defines yield point as the maximum load before the parallel portion of a tensile test specimen begins to yield, divided by its original cross-sectional area.
Plotting tensile test results as stress against strain—elongation divided by original length, expressed as a percentage—produces the stress–strain diagram shown.
After the initial straight rise, the curve drops sharply and then fluctuates. In this region, strain increases while stress changes little. This is called the yield region. The maximum stress in it is the upper yield point, and the minimum is the lower yield point. Where no confusion arises, the upper yield point may simply be called the yield point.
Some materials have no distinct upper yield point. For these, the 0.2% proof stress is used instead.
The catalog for ETP BUSH friction locking devices includes “Design Checks / Minimum Hub Outside Diameter Tables.” These tables give the minimum hub outside diameter for each ETP BUSH size and hub material.
The dimensions are calculated from the material’s yield point or 0.2% proof stress. The “0.2” designation in the table refers to this value: the stress at which 0.2% permanent strain is produced.
When an ETP BUSH secures a hub, its hub-side sleeve expands. If the hub outside diameter is smaller than the tabulated minimum, the hub may deform or fail. Yield point is therefore an important value for material selection, like tensile strength.
See “ETP-E Friction Locking Device: Operating Principle” and “ETP-A Friction Locking Device: Operating Principle.”
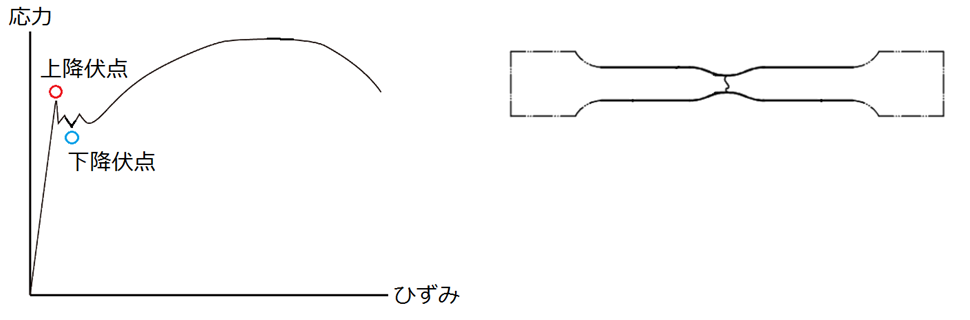
English translation of image text
• Stress
• Strain
• Upper yield point
• Lower yield point